Featured Publications
All Publications

People consider recommendations from AI systems in diverse domains ranging from recognizing tumors in medical images to deciding which shoes look cute with an outfit. Implicit in the decision process is the perceived expertise of the AI system. In this paper, we investigate how people trust and rely on an AI assistant that performs with different levels of expertise relative to the person, ranging from completely overlapping expertise to perfectly complementary expertise. Through a series of controlled online lab studies where participants identified objects with the help of an AI assistant, we demonstrate that participants were able to perceive when the assistant was an expert or non-expert within the same task and calibrate their reliance on the AI to improve team performance. We also demonstrate that communicating expertise through the linguistic properties of the explanation text was effective, where embracing language increased reliance and distancing language reduced reliance on AI. READ MORE
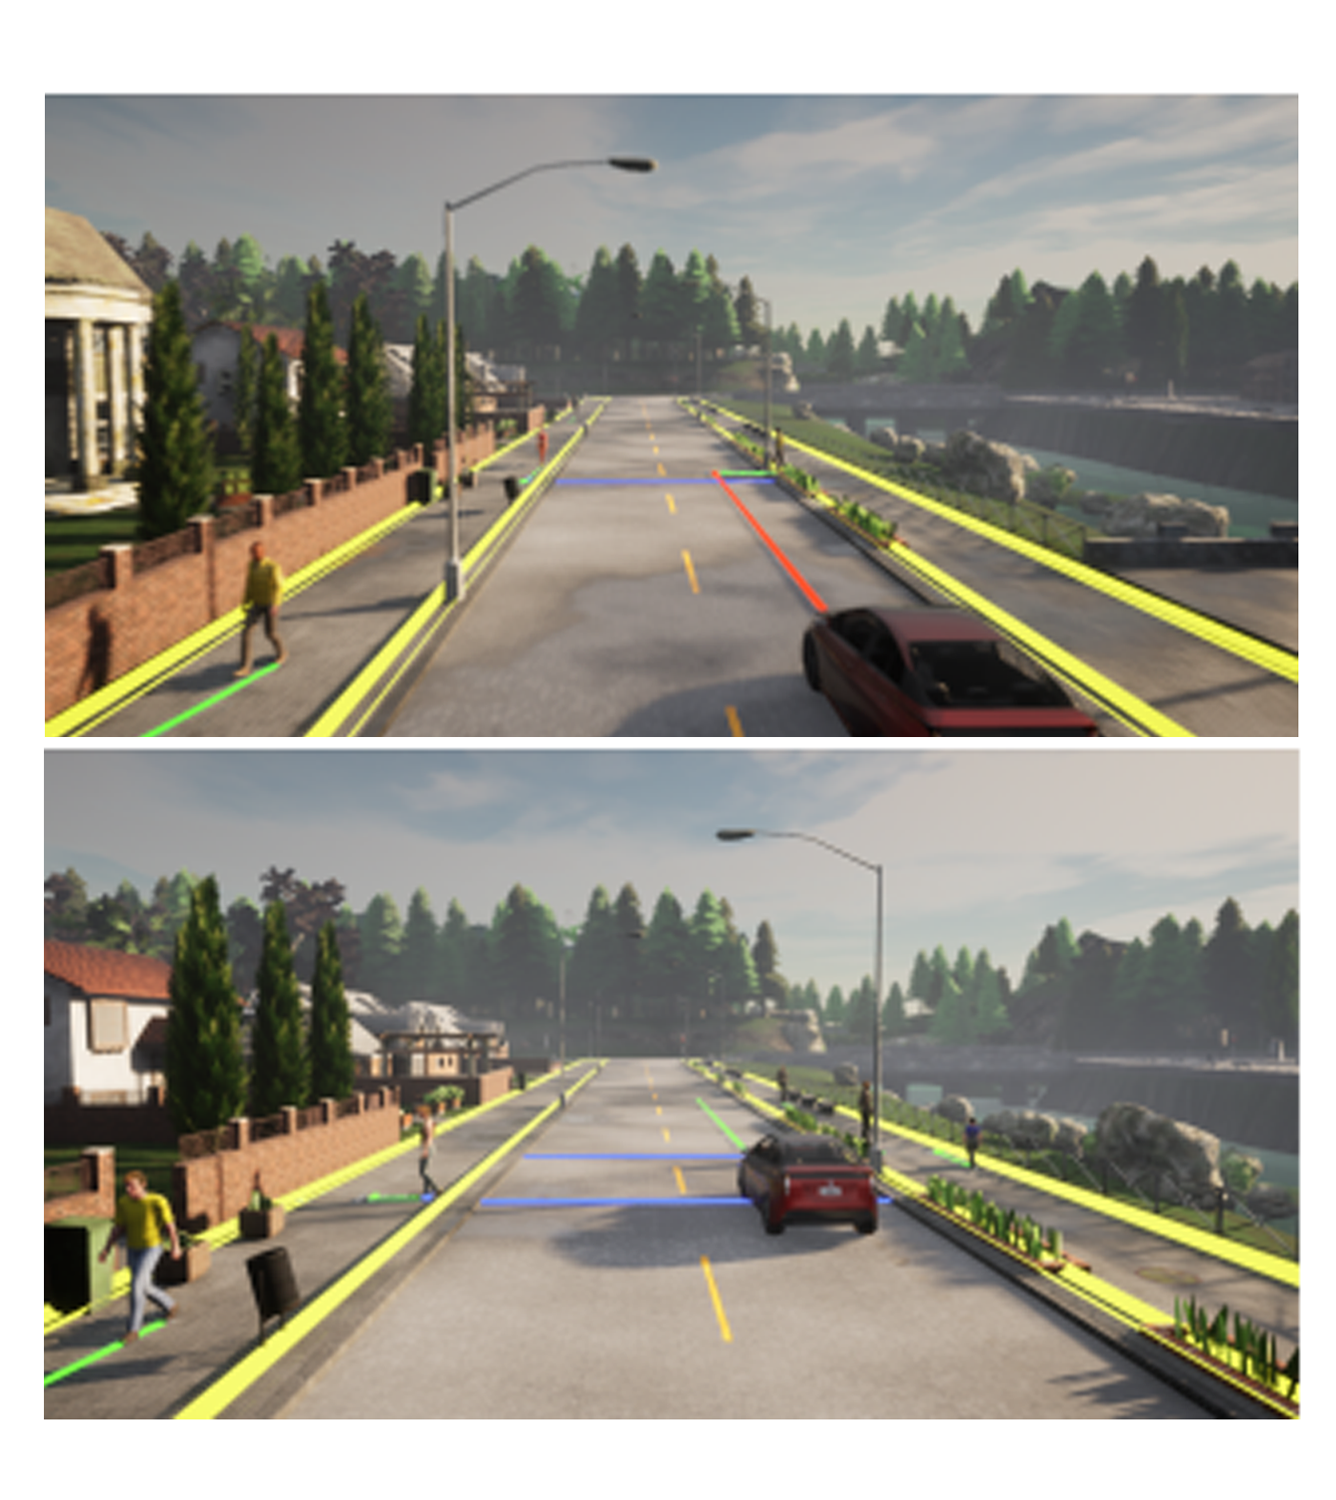
Autonomous vehicle software is typically structured as a modular pipeline of individual components (e.g., perception, prediction, and planning) to help separate concerns into interpretable sub-tasks. Even when end-to-end training is possible, each module has its own set of objectives used for safety assurance, sample efficiency, regularization, or interpretability. However, intermediate objectives do not always align with overall system performance. For example, optimizing the likelihood of a trajectory prediction module might focus more on easy-to-predict agents than safety-critical or rare behaviors (e.g., jaywalking). In this paper, we present control-aware prediction objectives (CAPOs), to evaluate the downstream effect of predictions on control without requiring the planner be differentiable. We propose two types of importance weights that weight the predictive likelihood: one using an attention model between agents, and another based on control variation when exchanging predicted trajectories for ground truth trajectories. Experimentally, we show our objectives improve overall system performance in suburban driving scenarios using the CARLA simulator. READ MORE
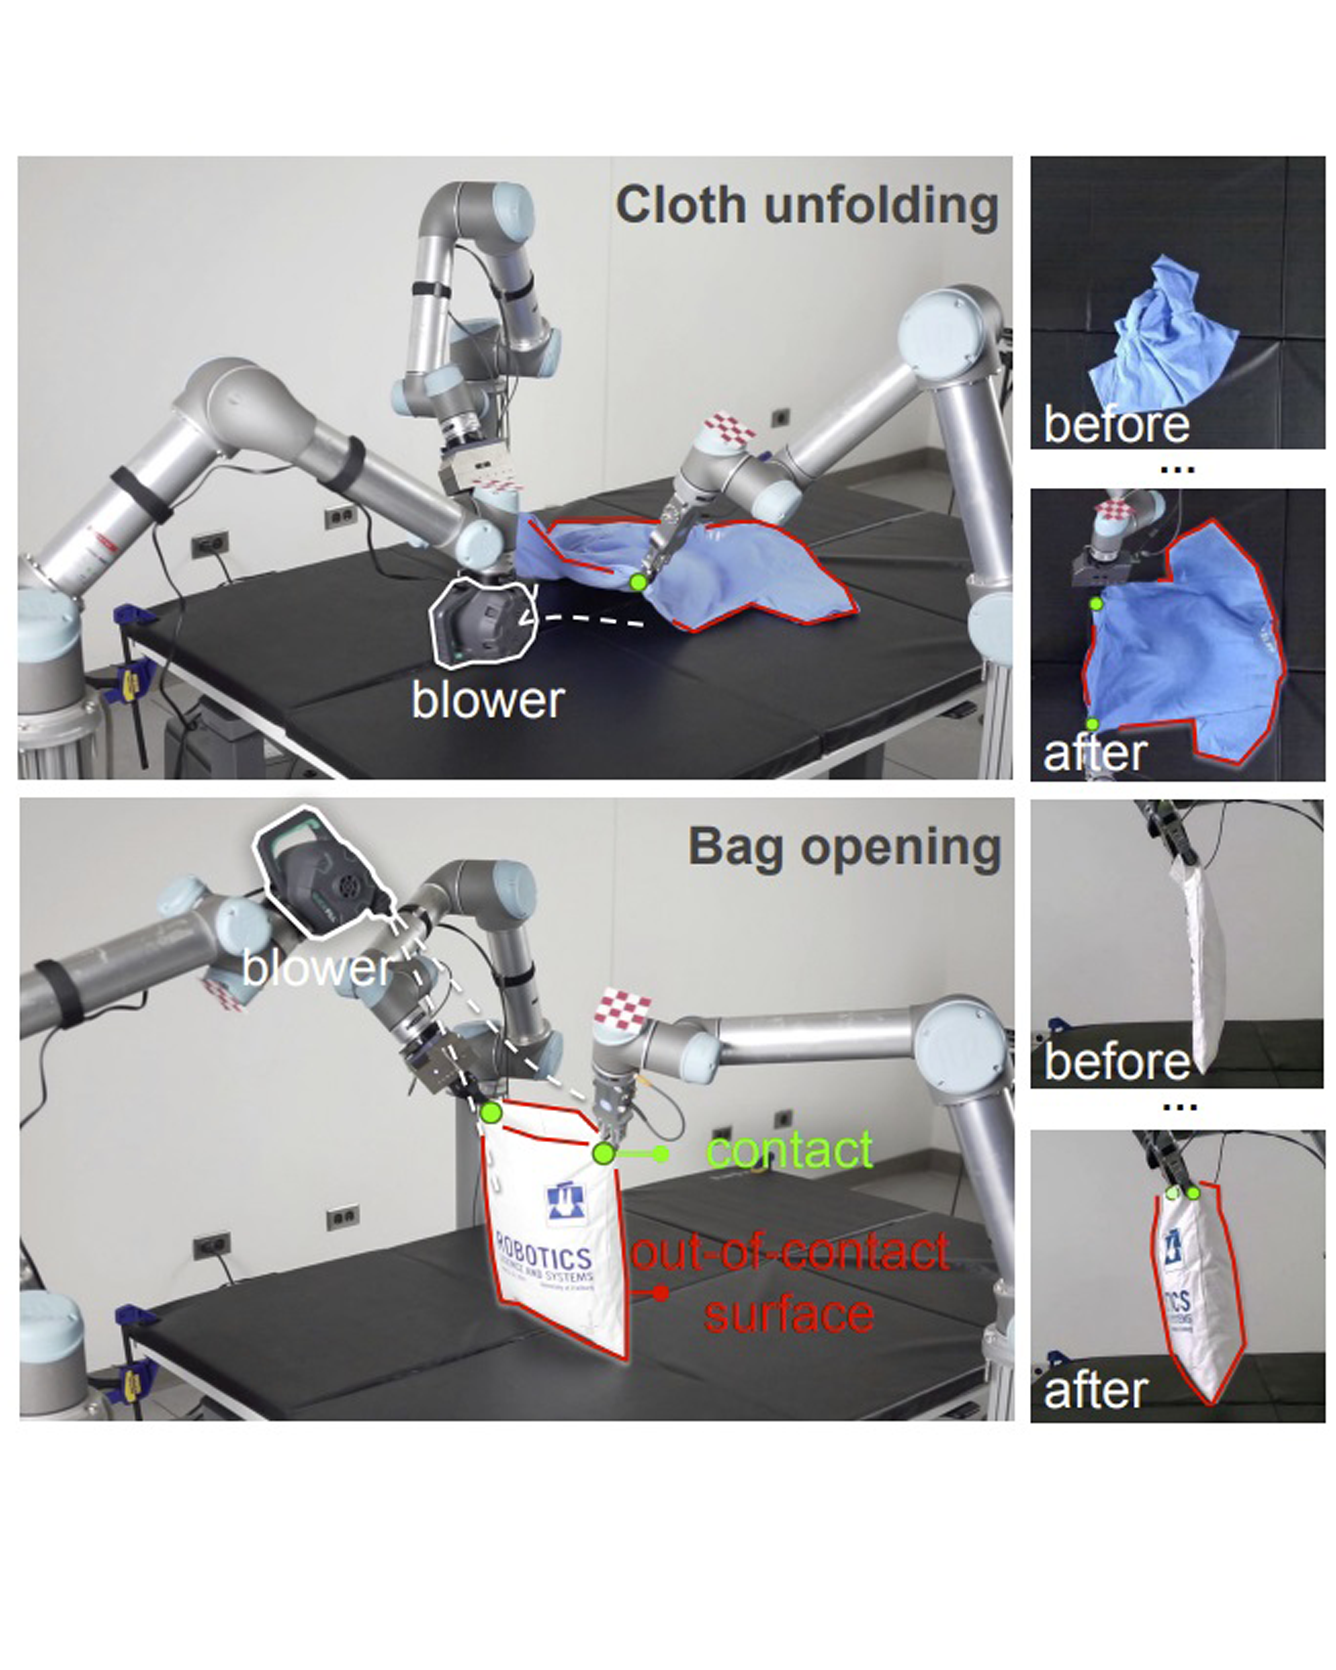
This paper introduces DextAIRity, an approach to manipulate deformable objects using active airflow. In contrast to conventional contact-based quasi-static manipulations, DextAIRity allows the system to apply dense forces on out-of-contact surfaces, expands the system's reach range, and provides safe high-speed interactions. These properties are particularly advantageous when manipulating under-actuated deformable objects with large surface areas or volumes. We demonstrate the effectiveness of DextAIRity through two challenging deformable object manipulation tasks: cloth unfolding and bag opening. We present a self-supervised learning framework that learns to effectively perform a target task through a sequence of grasping or air-based blowing actions. By using a closed-loop formulation for blowing, the system continuously adjusts its blowing direction based on visual feedback in a way that is robust to the highly stochastic dynamics. We deploy our algorithm on a real-world three-arm system and present evidence suggesting that DextAIRity can improve system efficiency for challenging deformable manipulation tasks, such as cloth unfolding, and enable new applications that are impractical to solve with quasi-static contact-based manipulations (e.g., bag opening). READ MORE
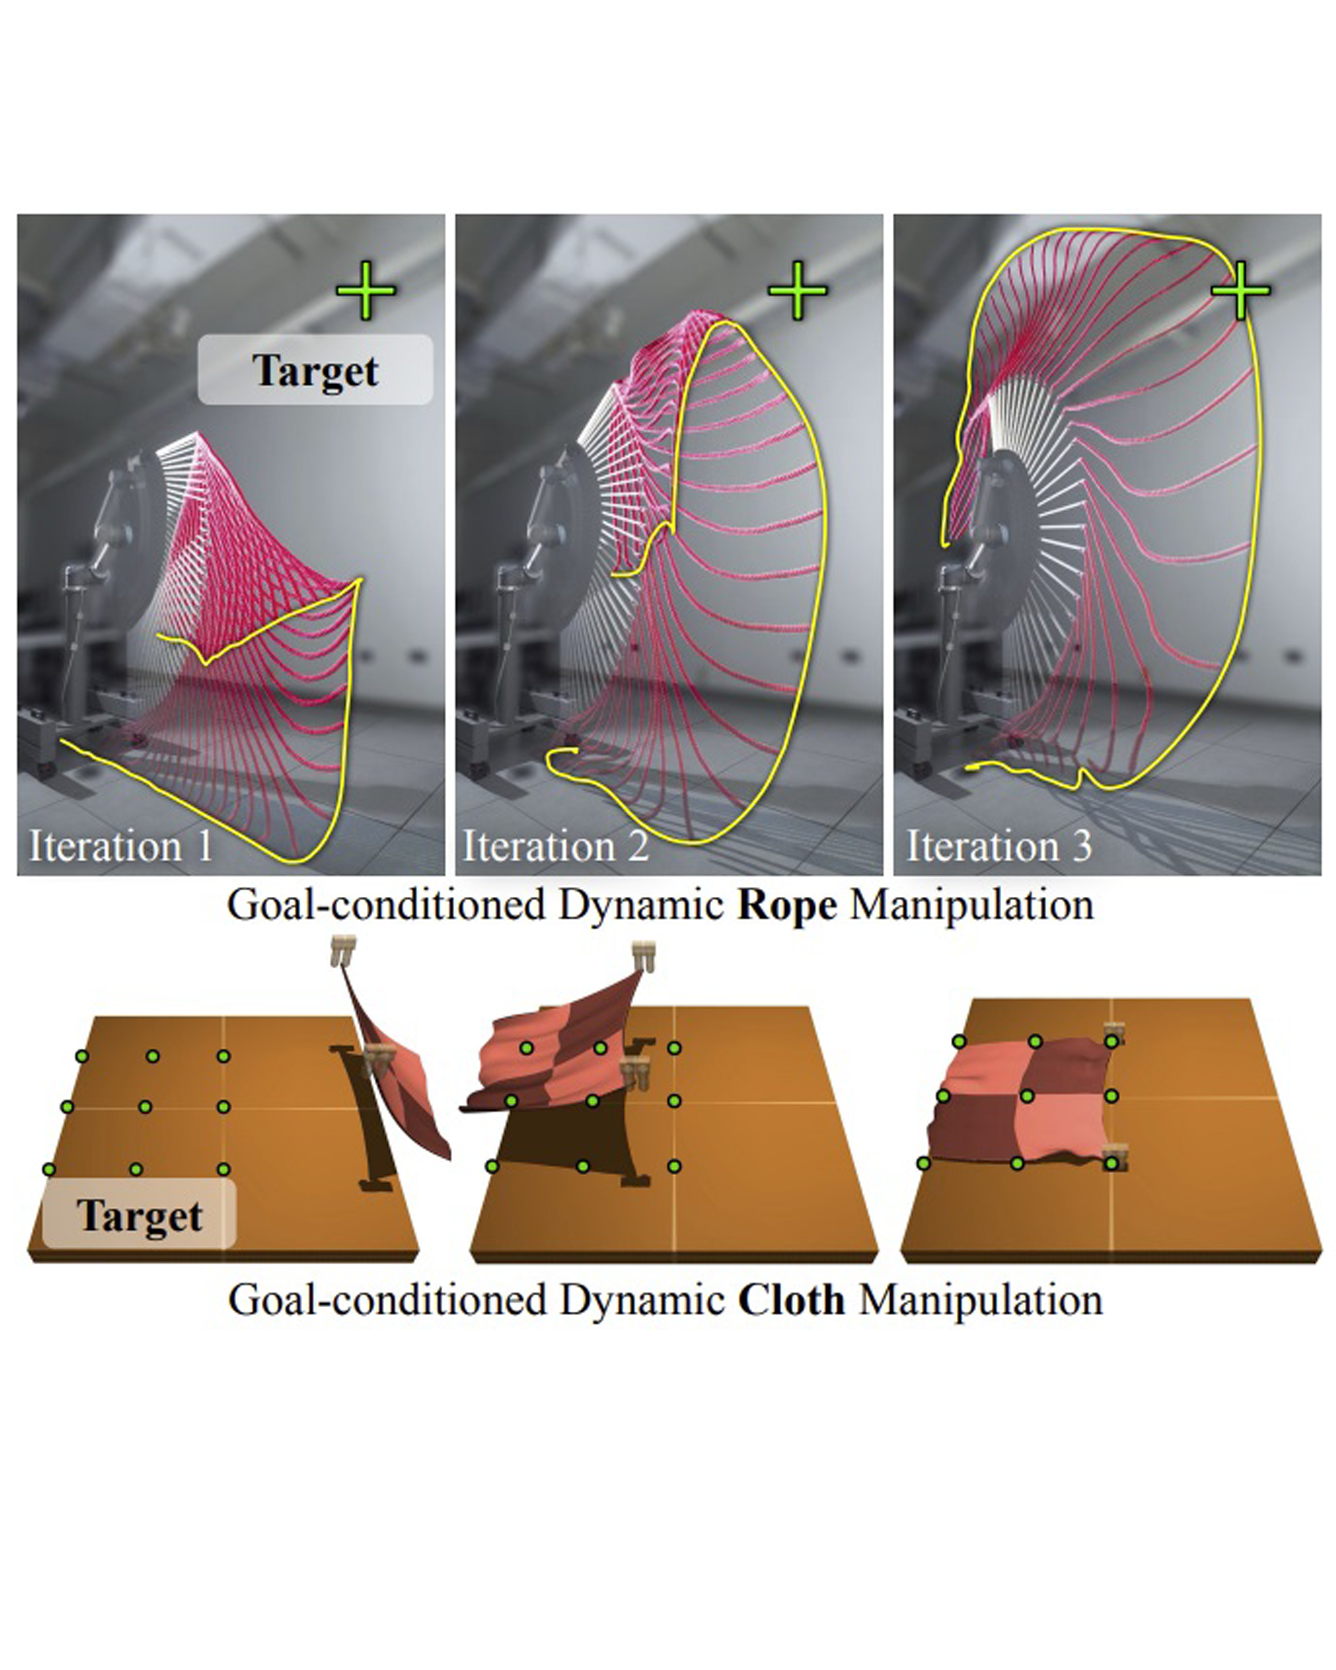
This paper tackles the task of goal-conditioned dynamic manipulation of deformable objects. This task is highly challenging due to its complex dynamics (introduced by object deformation and high-speed action) and strict task requirements (defined by a precise goal specification). To address these challenges, we present Iterative Residual Policy (IRP), a general learning framework applicable to repeatable tasks with complex dynamics. IRP learns an implicit policy via delta dynamics -- instead of modeling the entire dynamical system and inferring actions from that model, IRP learns delta dynamics that predict the effects of delta action on the previously-observed trajectory. When combined with adaptive action sampling, the system can quickly optimize its actions online to reach a specified goal. We demonstrate the effectiveness of IRP on two tasks: whipping a rope to hit a target point and swinging a cloth to reach a target pose. Despite being trained only in simulation on a fixed robot setup, IRP is able to efficiently generalize to noisy real-world dynamics, new objects with unseen physical properties, and even different robot hardware embodiments, demonstrating its excellent generalization capability relative to alternative approaches. READ MORE
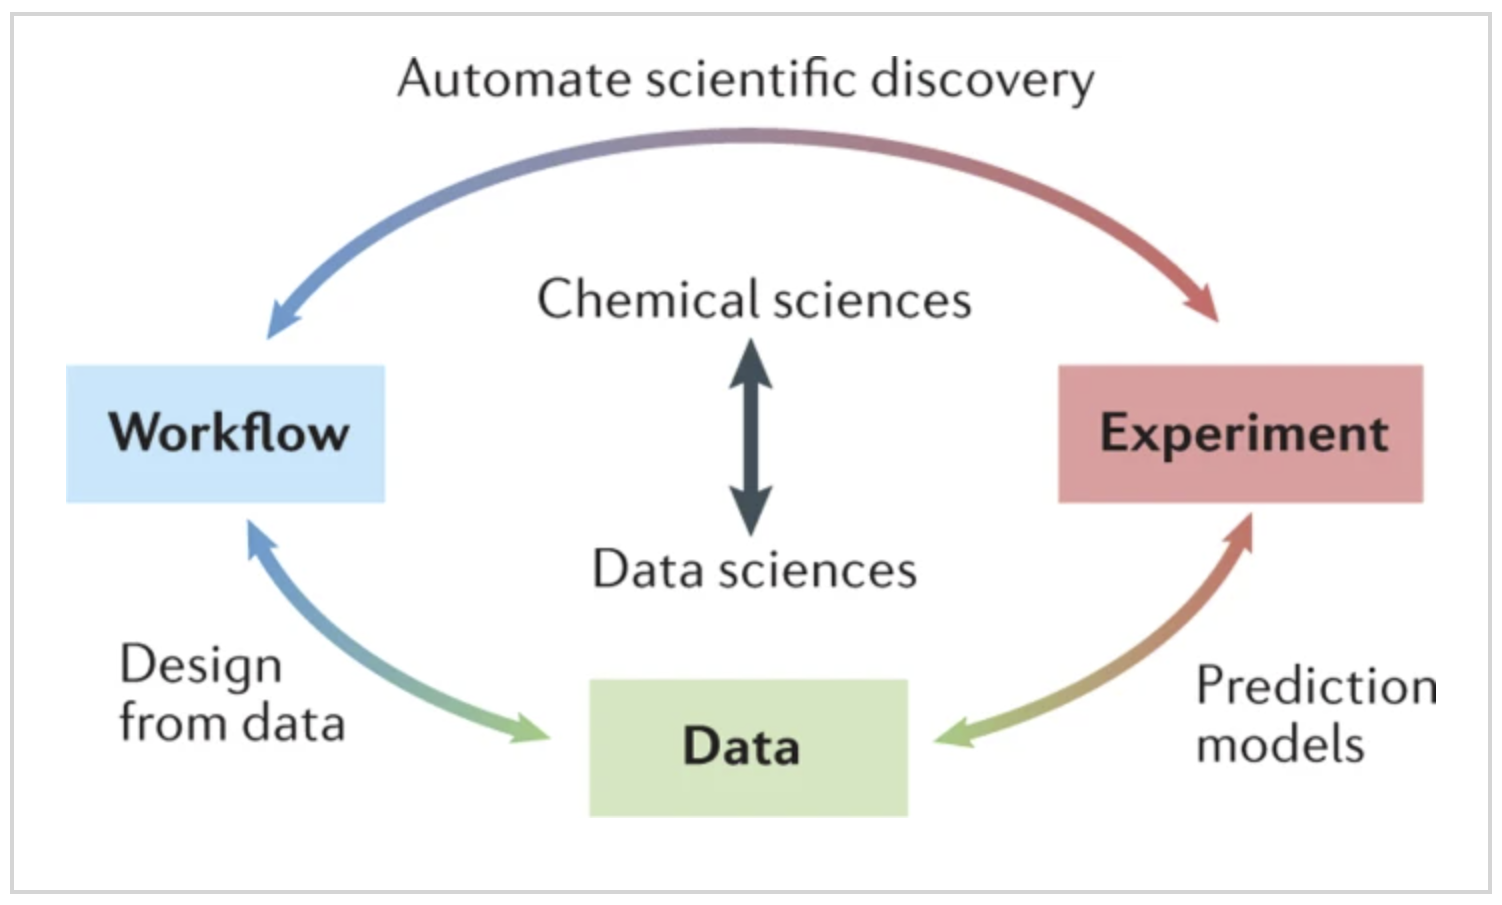
The physical sciences community is increasingly taking advantage of the possibilities offered by modern data science to solve problems in experimental chemistry and potentially to change the way we design, conduct and understand results from experiments. Successfully exploiting these opportunities involves considerable challenges. In this Expert Recommendation, we focus on experimental co-design and its importance to experimental chemistry. We provide examples of how data science is changing the way we conduct experiments, and we outline opportunities for further integration of data science and experimental chemistry to advance these fields. Our recommendations include establishing stronger links between chemists and data scientists; developing chemistry-specific data science methods; integrating algorithms, software and hardware to ‘co-design’ chemistry experiments from inception; and combining diverse and disparate data sources into a data network for chemistry research. READ MORE
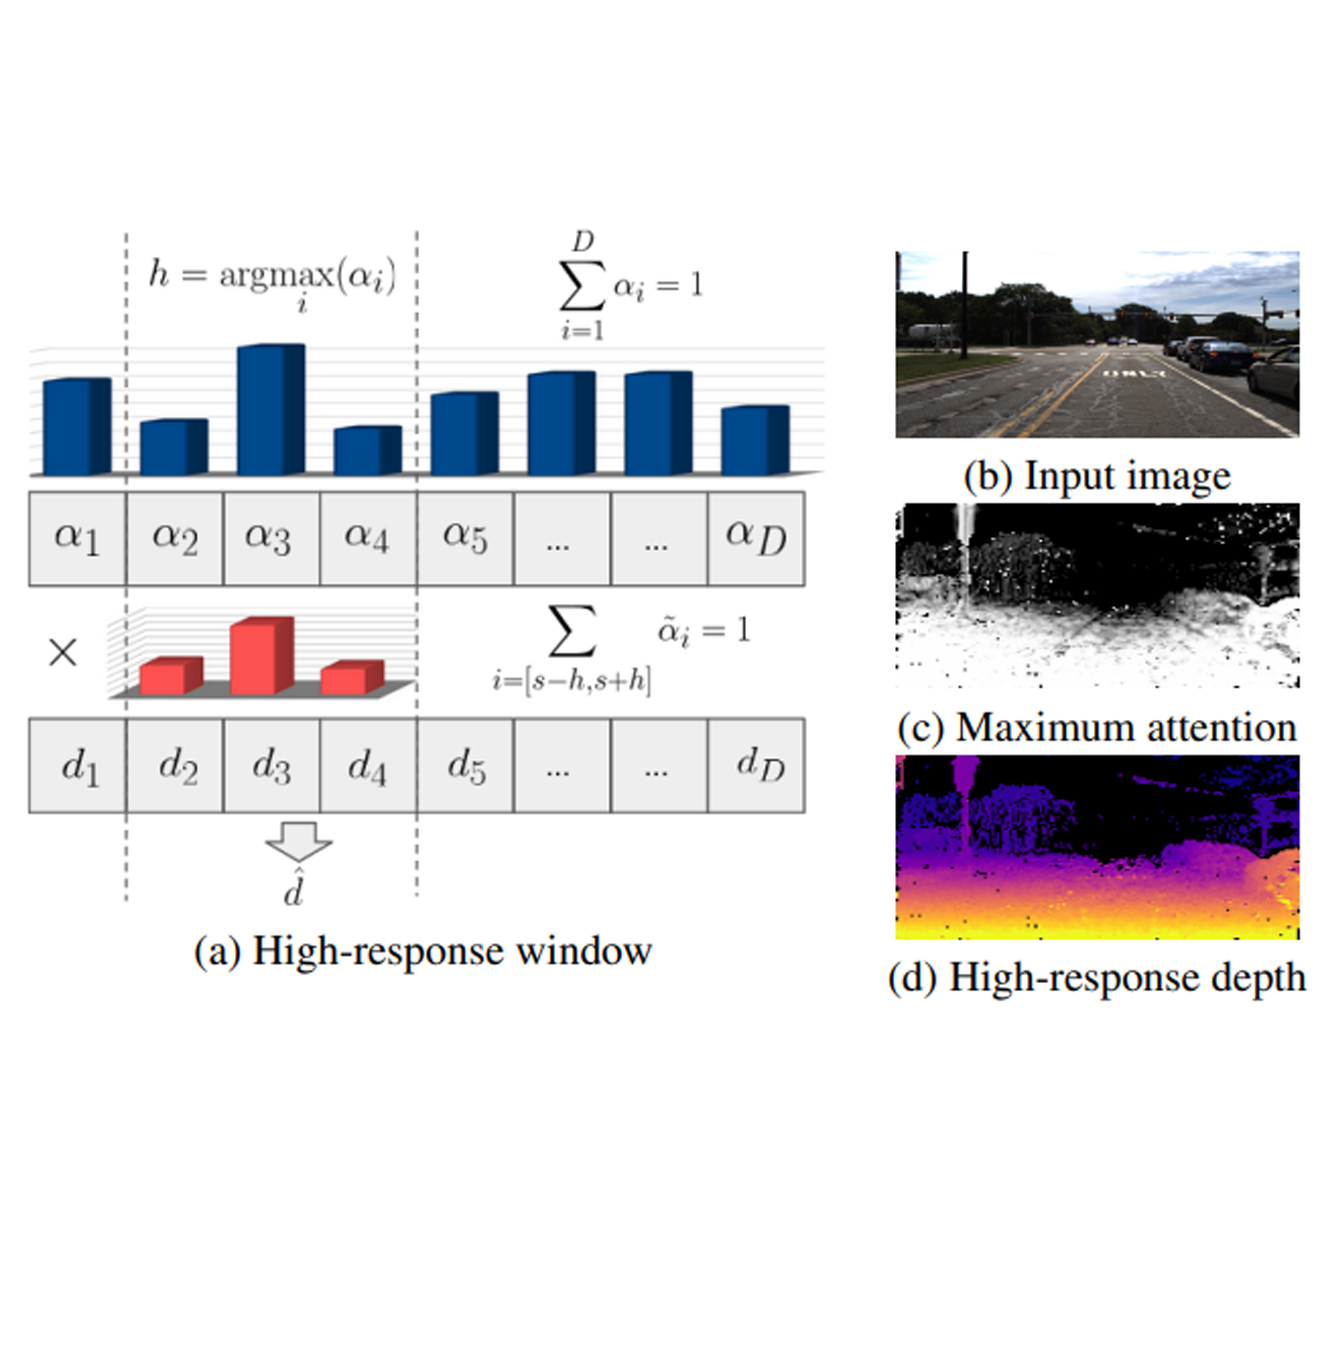
Multi-frame depth estimation improves over single-frame approaches by also leveraging geometric relationships between images via feature matching, in addition to learning appearance-based features. In this paper we revisit feature matching for self-supervised monocular depth estimation, and propose a novel transformer architecture for cost volume generation. We use depth-discretized epipolar sampling to select matching candidates, and refine predictions through a series of self- and cross-attention layers. These layers sharpen the matching probability between pixel features, improving over standard similarity metrics prone to ambiguities and local minima. The refined cost volume is decoded into depth estimates, and the whole pipeline is trained end-to-end from videos using only a photometric objective. Experiments on the KITTI and DDAD datasets show that our DepthFormer architecture establishes a new state of the art in self-supervised monocular depth estimation, and is even competitive with highly specialized supervised single-frame architectures. We also show that our learned cross-attention network yields representations transferable across datasets, increasing the effectiveness of pre-training strategies. READ MORE
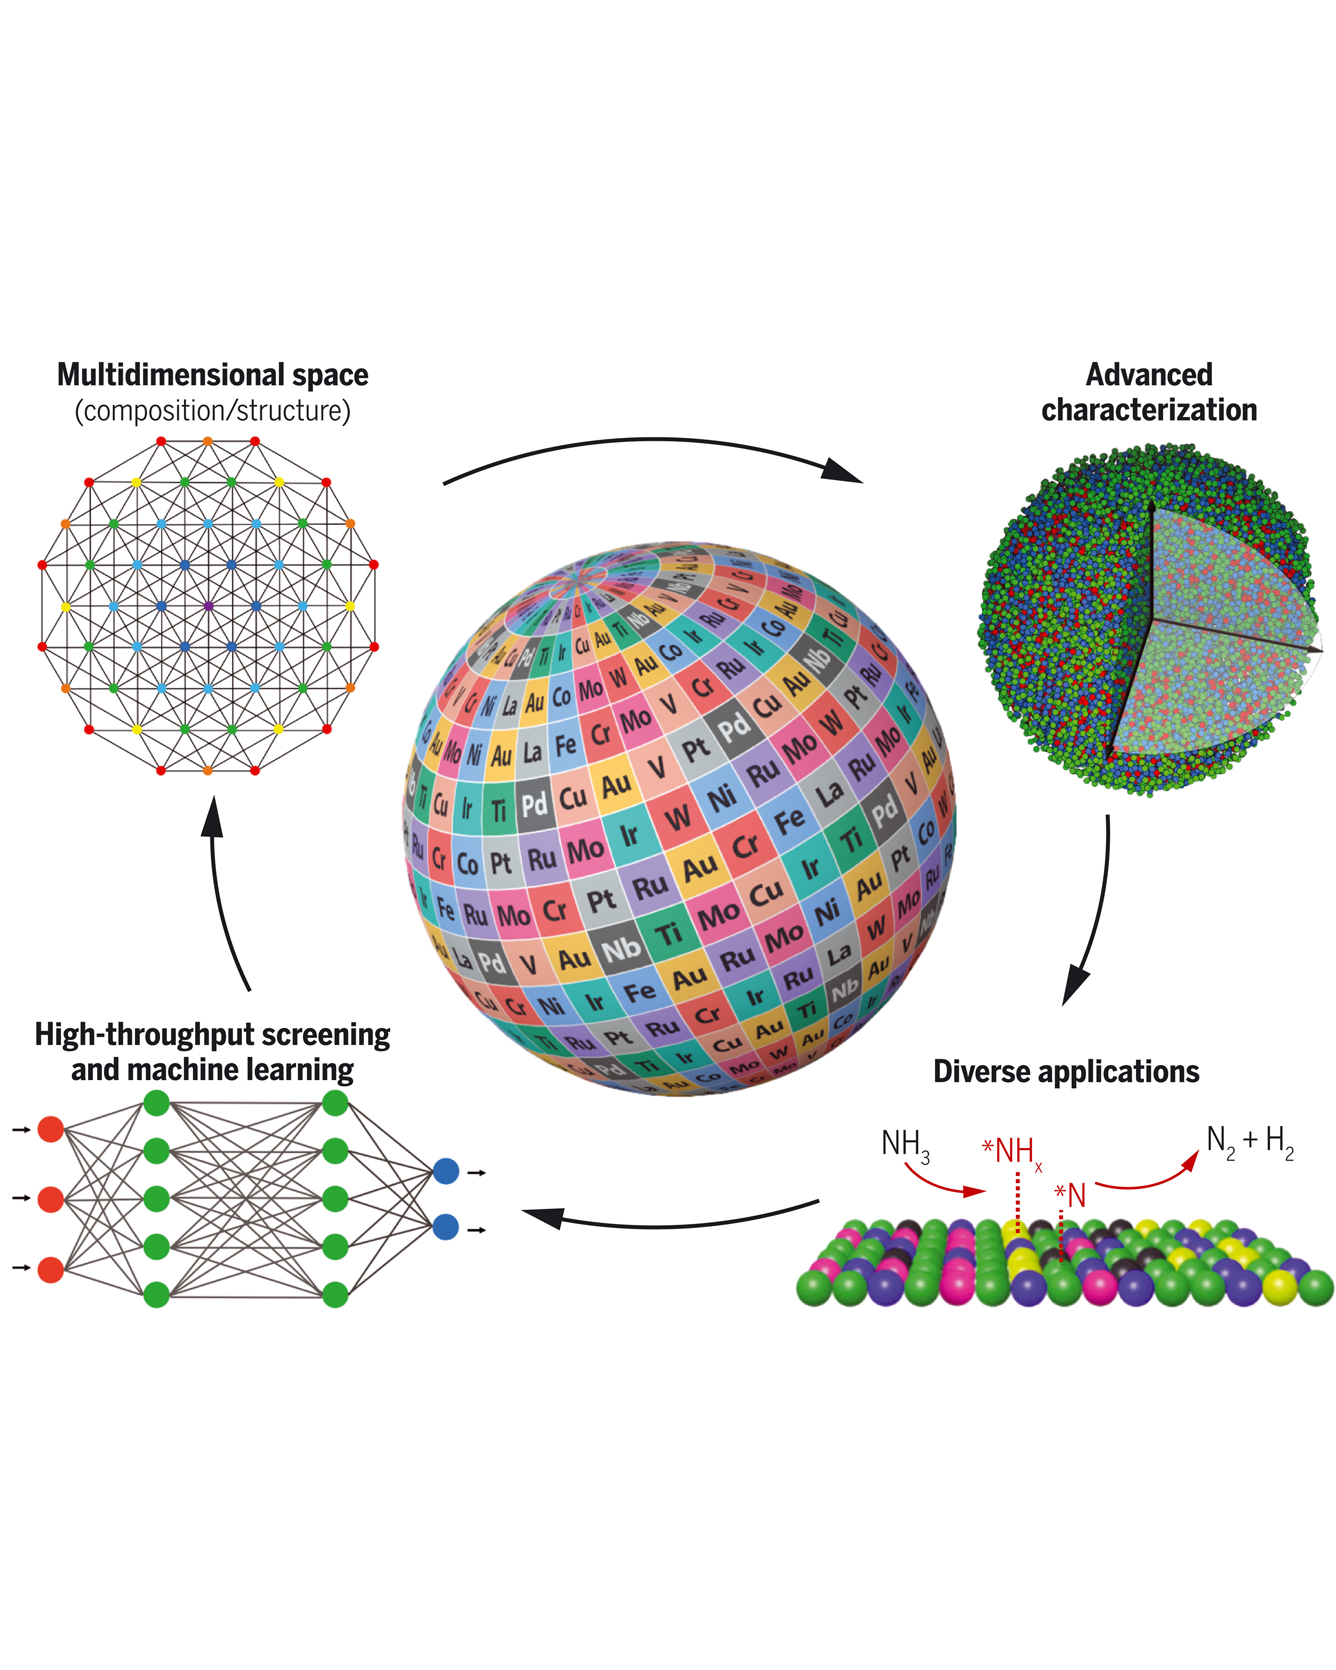
High-entropy nanoparticles have become a rapidly growing area of research in recent years. Because of their multielemental compositions and unique high-entropy mixing states (i.e., solid-solution) that can lead to tunable activity and enhanced stability, these nanoparticles have received notable attention for catalyst design and exploration. However, this strong potential is also accompanied by grand challenges originating from their vast compositional space and complex atomic structure, which hinder comprehensive exploration and fundamental understanding. Through a multidisciplinary view of synthesis, characterization, catalytic applications, high-throughput screening, and data-driven materials discovery, this review is dedicated to discussing the important progress of high-entropy nanoparticles and unveiling the critical needs for their future development for catalysis, energy, and sustainability applications. READ MORE
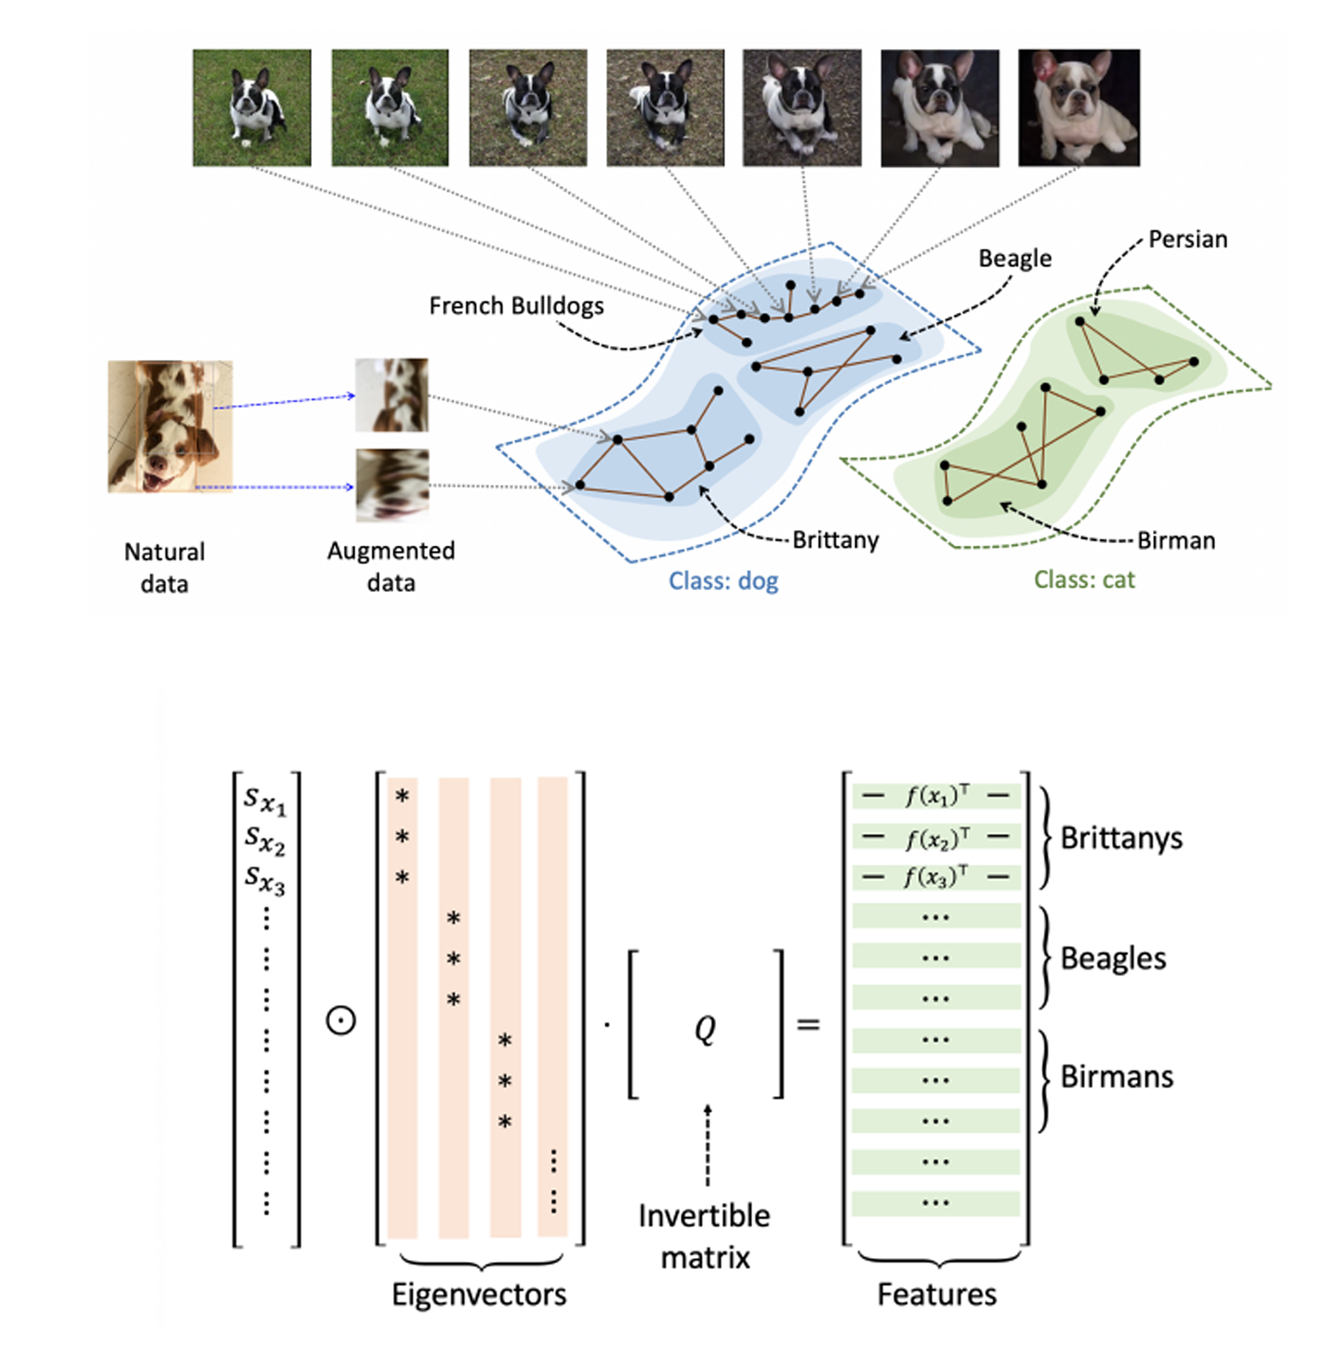
Recent works in self-supervised learning have advanced the state-of-the-art by relying on the contrastive learning paradigm, which learns representations by pushing positive pairs, or similar examples from the same class, closer together while keeping negative pairs far apart. Despite the empirical successes, theoretical foundations are limited – prior analyses assume conditional independence of the positive pairs given the same class label, but recent empirical applications use heavily correlated positive pairs (i.e., data augmentations of the same image). Our work analyzes contrastive learning without assuming conditional independence of positive pairs using a novel concept of the augmentation graph on data. Edges in this graph connect augmentations of the same datapoint, and ground-truth classes naturally form connected sub-graphs. We propose a loss that performs spectral decomposition on the population augmentation graph and can be succinctly written as a contrastive learning objective on neural net representations. Minimizing this objective leads to features with provable accuracy guarantees under linear probe evaluation. By standard generalization bounds, these accuracy guarantees also hold when minimizing the training contrastive loss. Empirically, the features learned by our objective can match or outperform several strong baselines on benchmark vision datasets. In all, this work provides the first provable analysis for contrastive learning where guarantees for linear probe evaluation can apply to realistic empirical settings. READ MORE
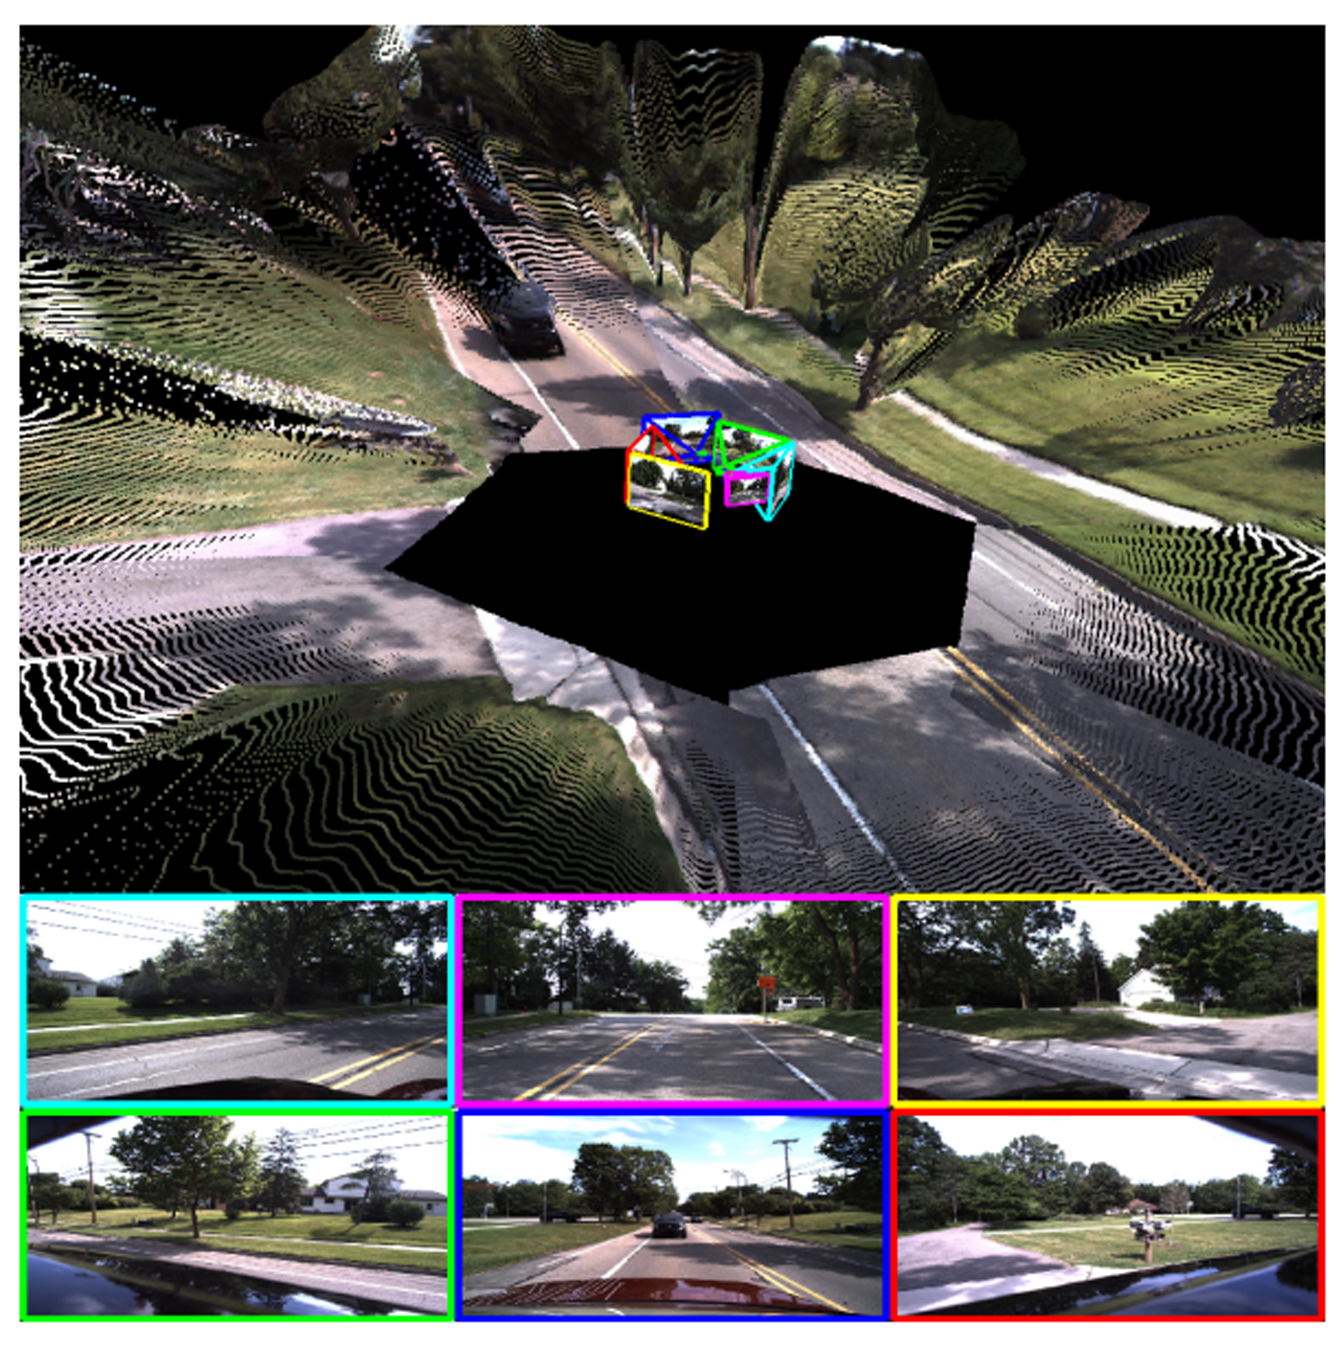
Self-supervised monocular depth and ego-motion estimation is a promising approach to replace or supplement expensive depth sensors such as LiDAR for robotics applications like autonomous driving. However, most research in this area focuses on a single monocular camera or stereo pairs that cover only a fraction of the scene around the vehicle. In this work, we extend monocular self-supervised depth and ego-motion estimation to large-baseline multi-camera rigs. Using generalized spatio-temporal contexts, pose consistency constraints, and carefully designed photometric loss masking, we learn a single network generating dense, consistent, and scale-aware point clouds that cover the same full surround 360 degree field of view as a typical LiDAR scanner. We also propose a new scale-consistent evaluation metric more suitable to multi-camera settings. Experiments on two challenging benchmarks illustrate the benefits of our approach over strong baselines. READ MORE
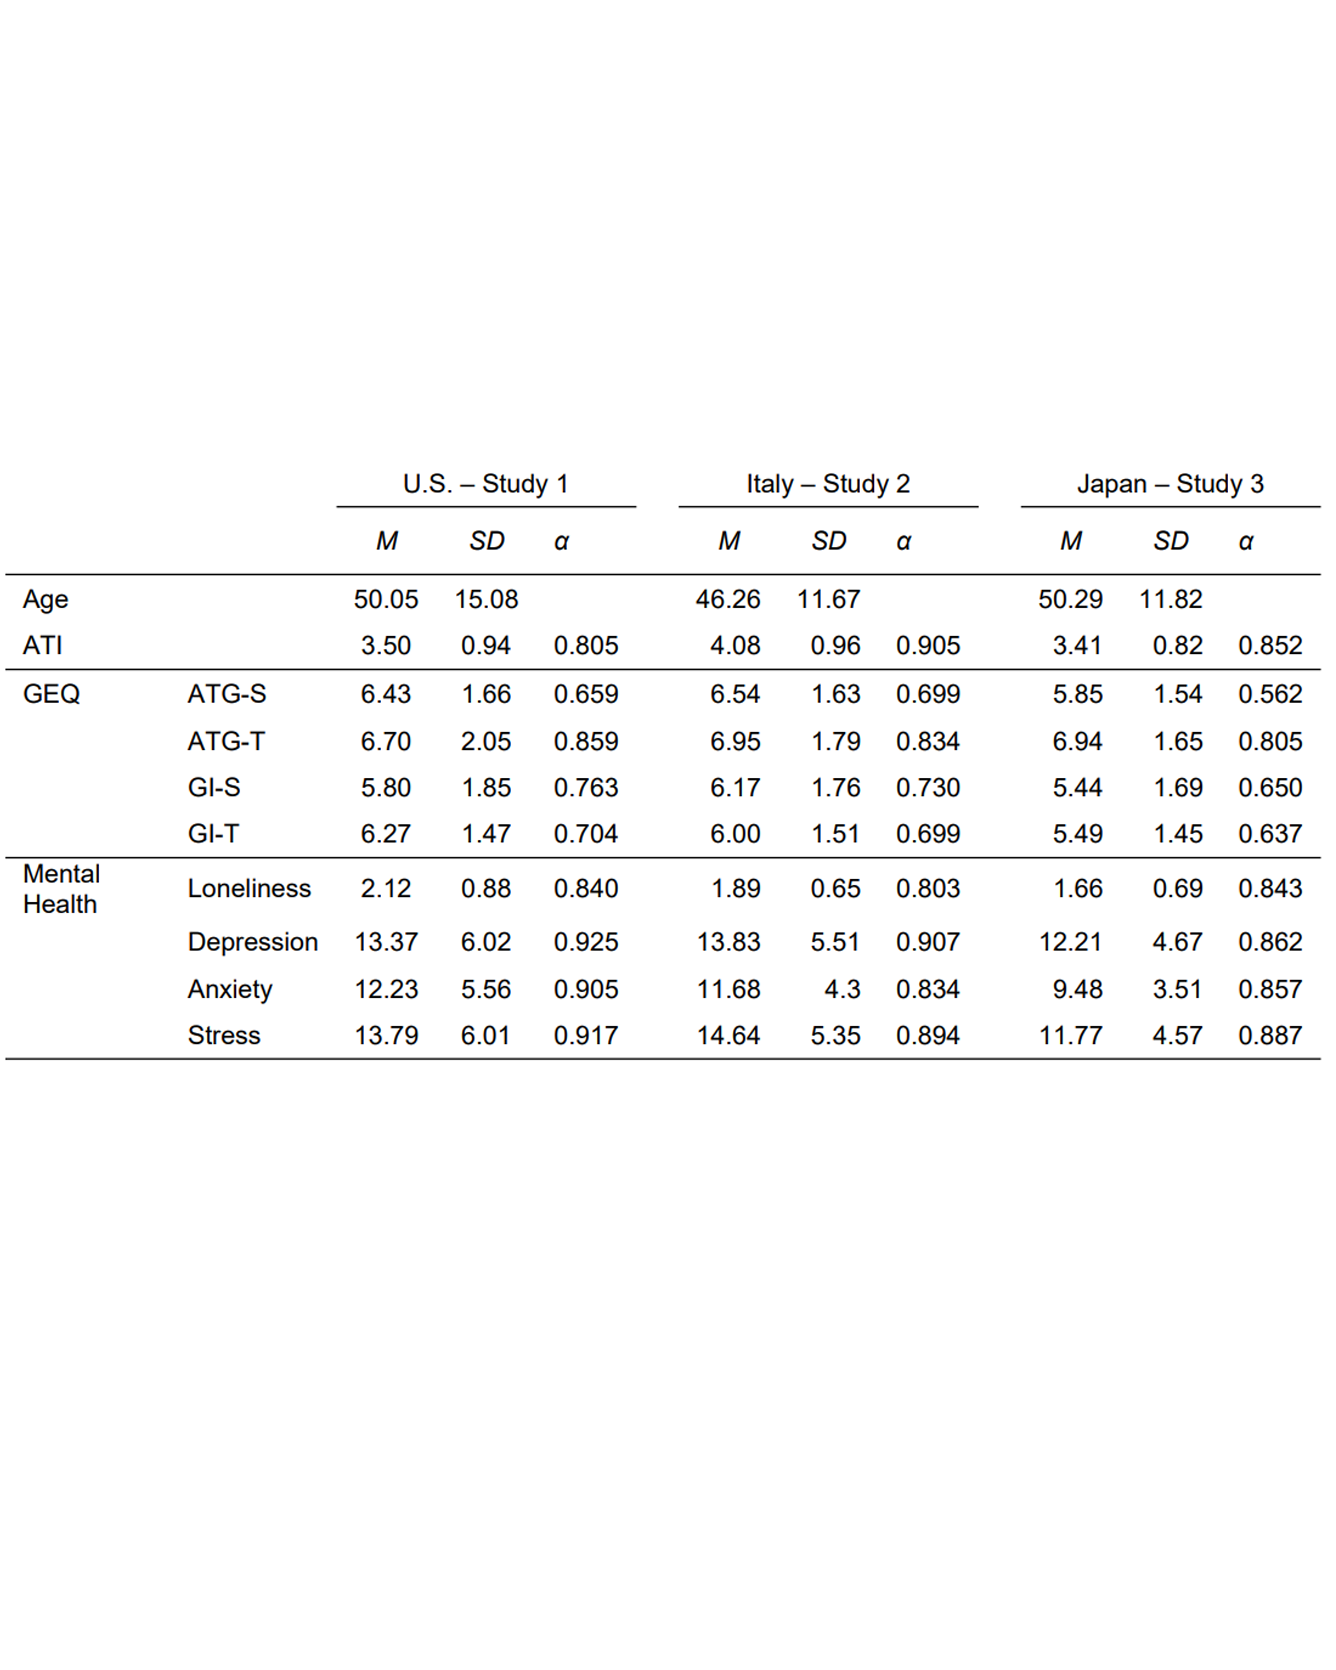
Group cohesion and social contact with other people is critical for supporting mental health (defined here as reduced loneliness, depression, anxiety, stress). Sometimes it is difficult to interact with social groups in person because of distance, poor health, or a global pandemic. In such cases, people can maintain social contact through technology like instant messaging, audio calls, and video calls. Age plays a major role in mental health and technology use: Age typically correlates with worse mental health and poor technology use, which could doubly harm older adults when most of their social connection can only be made through technology. However, some studies have shown that older adults can be quite capable of using technology and use it differently than younger adults. In this study, we sought a deeper understanding of the relationship between participants’ age and their use of and affinity for technology on group cohesion and mental health during social isolation. To do so, we surveyed participants in the United States (U.S.; Study 1, N = 202), Italy (Study 2, N = 325), and Japan (Study 3, N = 261) during a time of increased social isolation due to quarantine restrictions for the COVID-19 pandemic. Results indicated that greater affinity for technology related to worse group cohesion and mental health for younger adults , but better group cohesion and mental health for older adults . Certain subtypes of group cohesion (group integration for social purposes; GI-S) related to better mental health for younger adults and others (group integration for task purposes; GI-T) related to better mental health for older adults. Effects of age in group cohesion replicated across countries, although which specific mental health measures showed effects depended on country. Future studies of technology use and needs should differentiate populations based on age, technology use, and affinity for technology to provide further insights into how technology can best support group cohesion and mental health. Read More