Featured Publications
All Publications

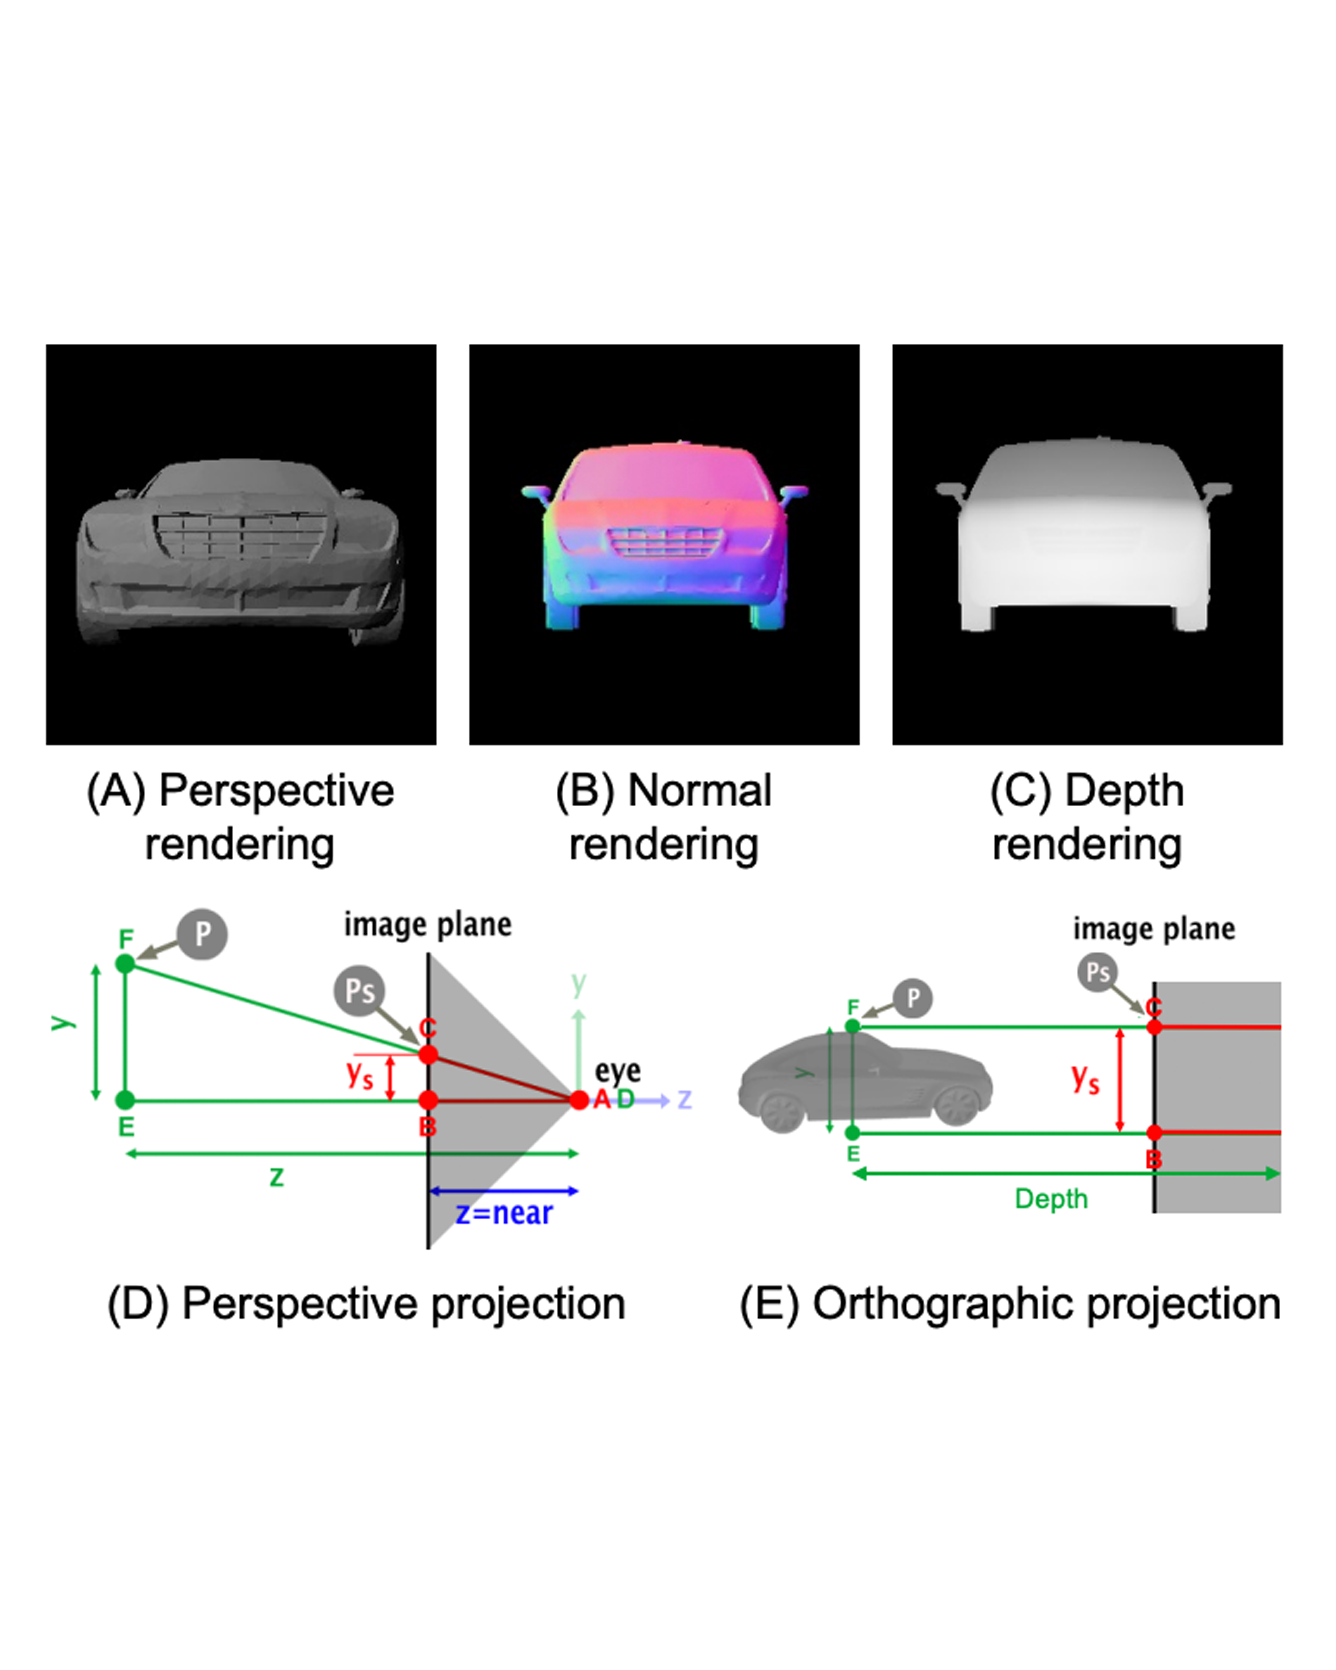
Generative AI models have made significant progress in automating the creation of 3D shapes, which has the potential to transform car design. In engineering design and optimization, evaluating engineering metrics is crucial. To make generative models performance-aware and enable them to create high-performing designs, surrogate modeling of these metrics is necessary. However, the currently used representations of 3D shapes either require extensive computational resources to learn or suffer from significant information loss, which impairs their effectiveness in surrogate modeling. To address this issue, we propose a new 2D representation of 3D shapes. We develop a surrogate drag model based on this representation to verify its effectiveness in predicting 3D car drag. We construct a diverse dataset of 4,535 high-quality 3D car meshes labeled by drag coefficients computed from computational fluid dynamics simulations to train our model. Our experiments demonstrate that our model can accurately and efficiently evaluate drag coefficients with an R^2 value above 0.84 for various car categories. Our model is implemented using deep neural networks, making it compatible with recent AI image generation tools (such as Stable Diffusion) and a significant step towards the automatic generation of drag-optimized car designs. Moreover, we demonstrate a case study using the proposed surrogate model to guide a diffusion-based deep generative model for drag-optimized car body synthesis. We have made the dataset and code publicly available at https://decode.mit.edu/projects/dragprediction/. READ MORE
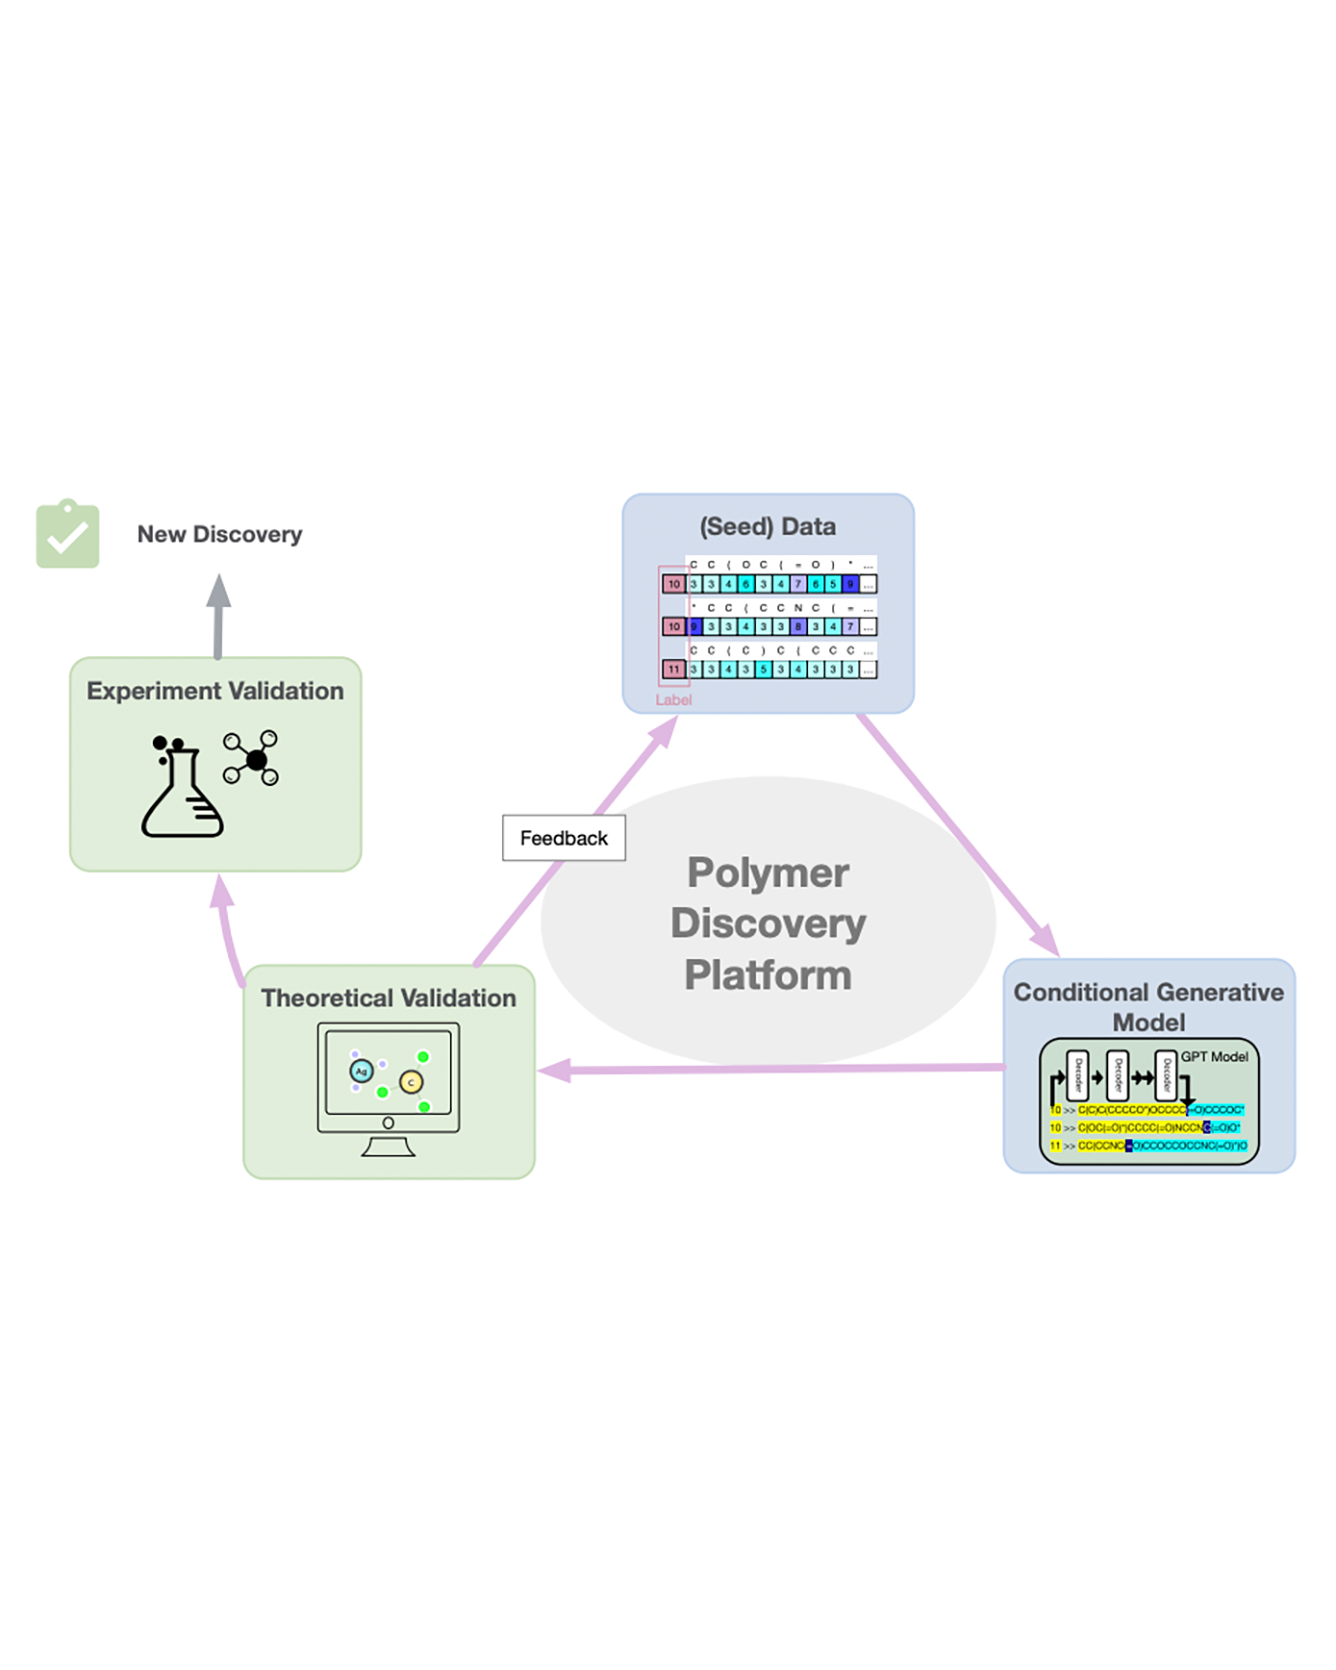
In this work, we introduce a polymer discovery platform designed to identify polymers with tailored properties efficiently, exemplified through the discovery of high-performance polymer electrolytes. The platform integrates three core components: a conditioned generative model, validation modules, and a feedback mechanism, creating a self-improving system for material innovation. To demonstrate the efficacy of this platform, it is used to identify polymer electrolyte materials with high ionic conductivity. A simple conditional generative model, based on the minGPT architecture, can effectively generate candidate polymers that exhibit a mean ionic conductivity that is significantly greater than those in the original training set. This approach, coupled with molecular dynamics simulations for validation and a specifically designed acquisition mechanism, allows the platform to refine its output iteratively. Notably, after the first iteration, we observed an increase in both the mean and the lower bound of the ionic conductivity of the new polymer candidates. The platform's effectiveness is underscored by the identification of 19 polymer repeating units, each displaying a computed ionic conductivity surpassing that of Polyethylene Oxide (PEO). The discovery of these polymers validates the platform's efficacy in identifying potential polymer materials. Acknowledging current limitations, future work will focus on enhancing modeling techniques, validation processes, and acquisition strategies, aiming for broader applicability in polymer science and machine learning. READ MORE
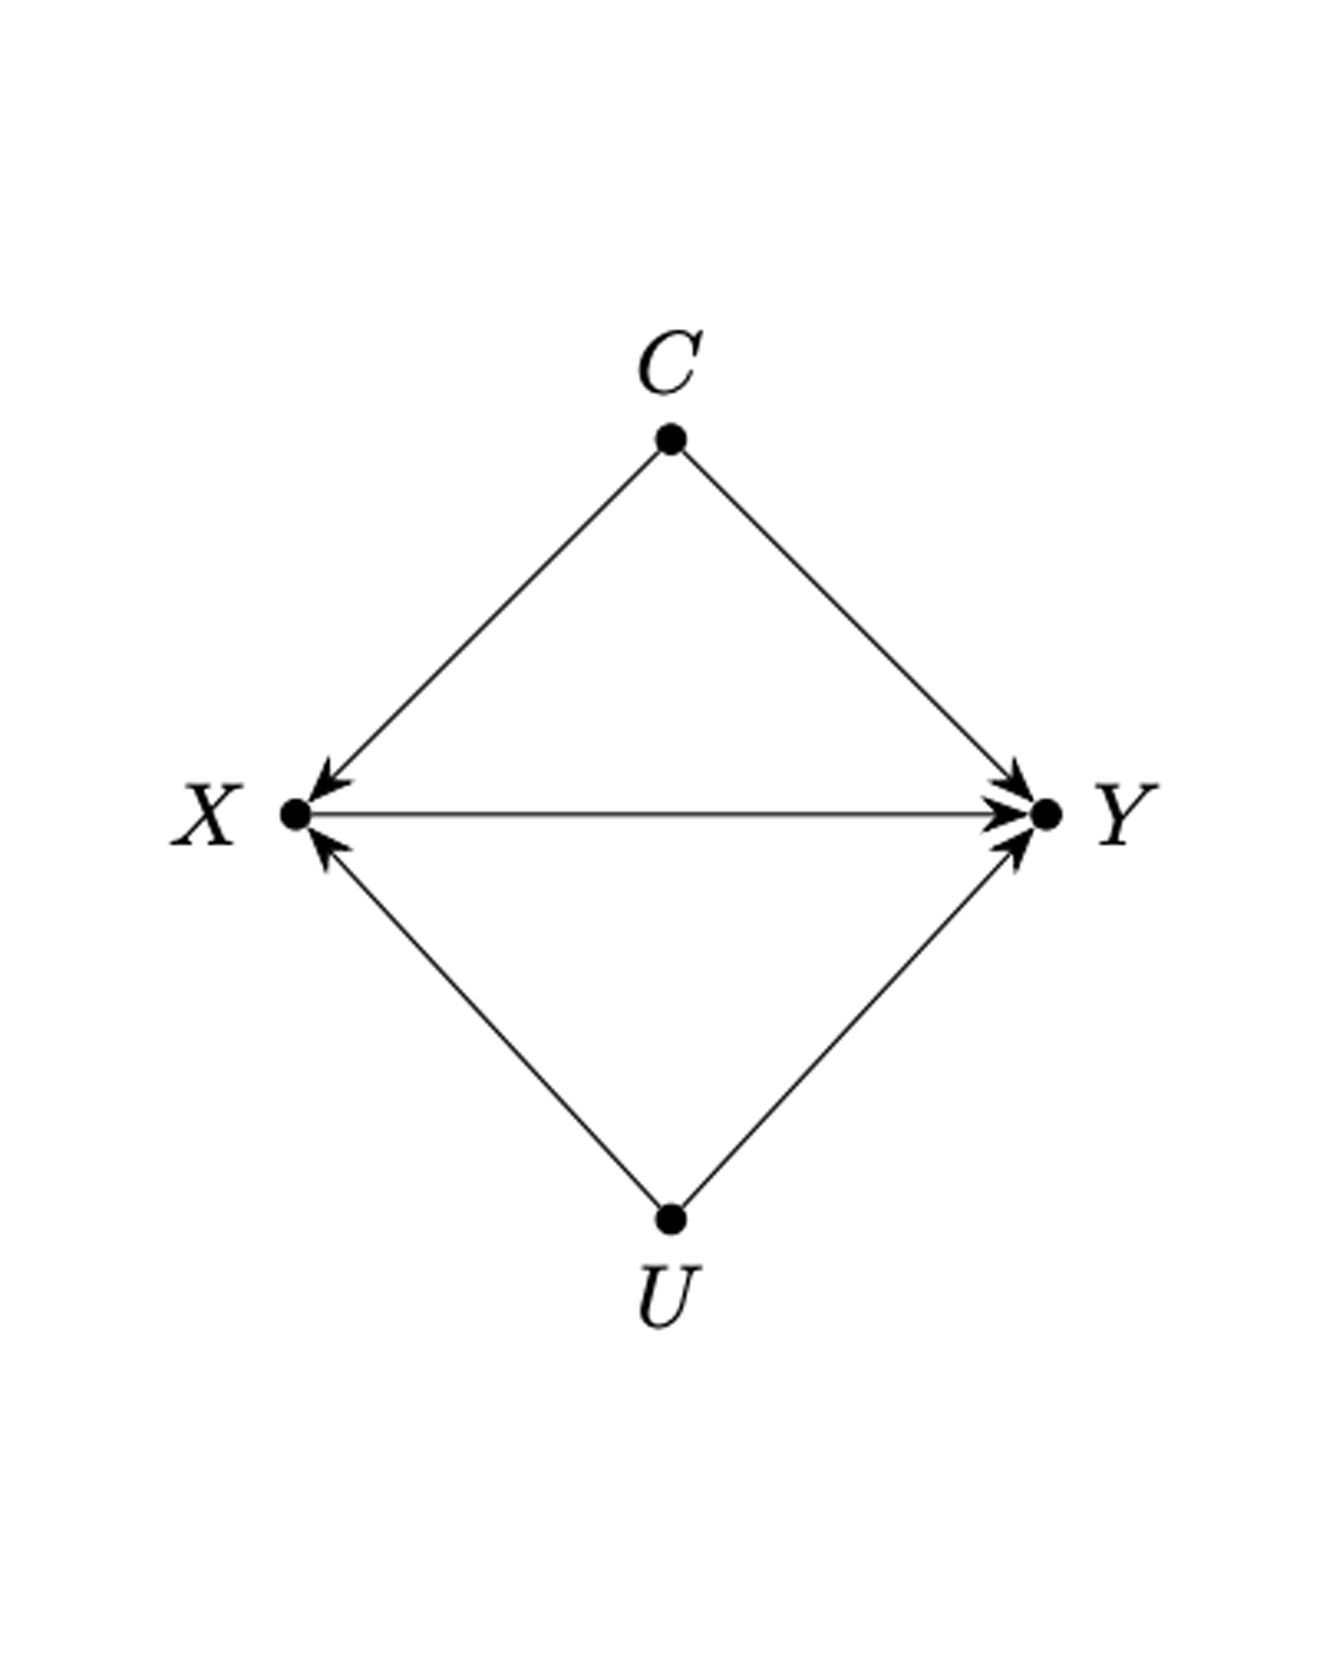
Electric vehicles (EVs) are generally considered more environmentally sustainable than internal combustion engine vehicles (ICEVs). Government and policy makers may want to incentivize multi-vehicle households who, if they purchase a new EV, would use their EV to replace a large portion of their ICEV mileage. Therefore, it is important to analyze how EV procurement affects annual EV mileage for different households. Given that many relevant data, especially experimental data, are often unavailable in the real world, we need causal analysis tools to answer this question. Additionally, our aim is to compare the expected EV mileage of different combinations of vehicles a household owns. Observing multiple combinations in an individual household is impossible since only one combination can exist, making causal inference challenging. In this paper, we construct a causal AI framework utilizing counterfactual reasoning methods to address this issue. READ MORE
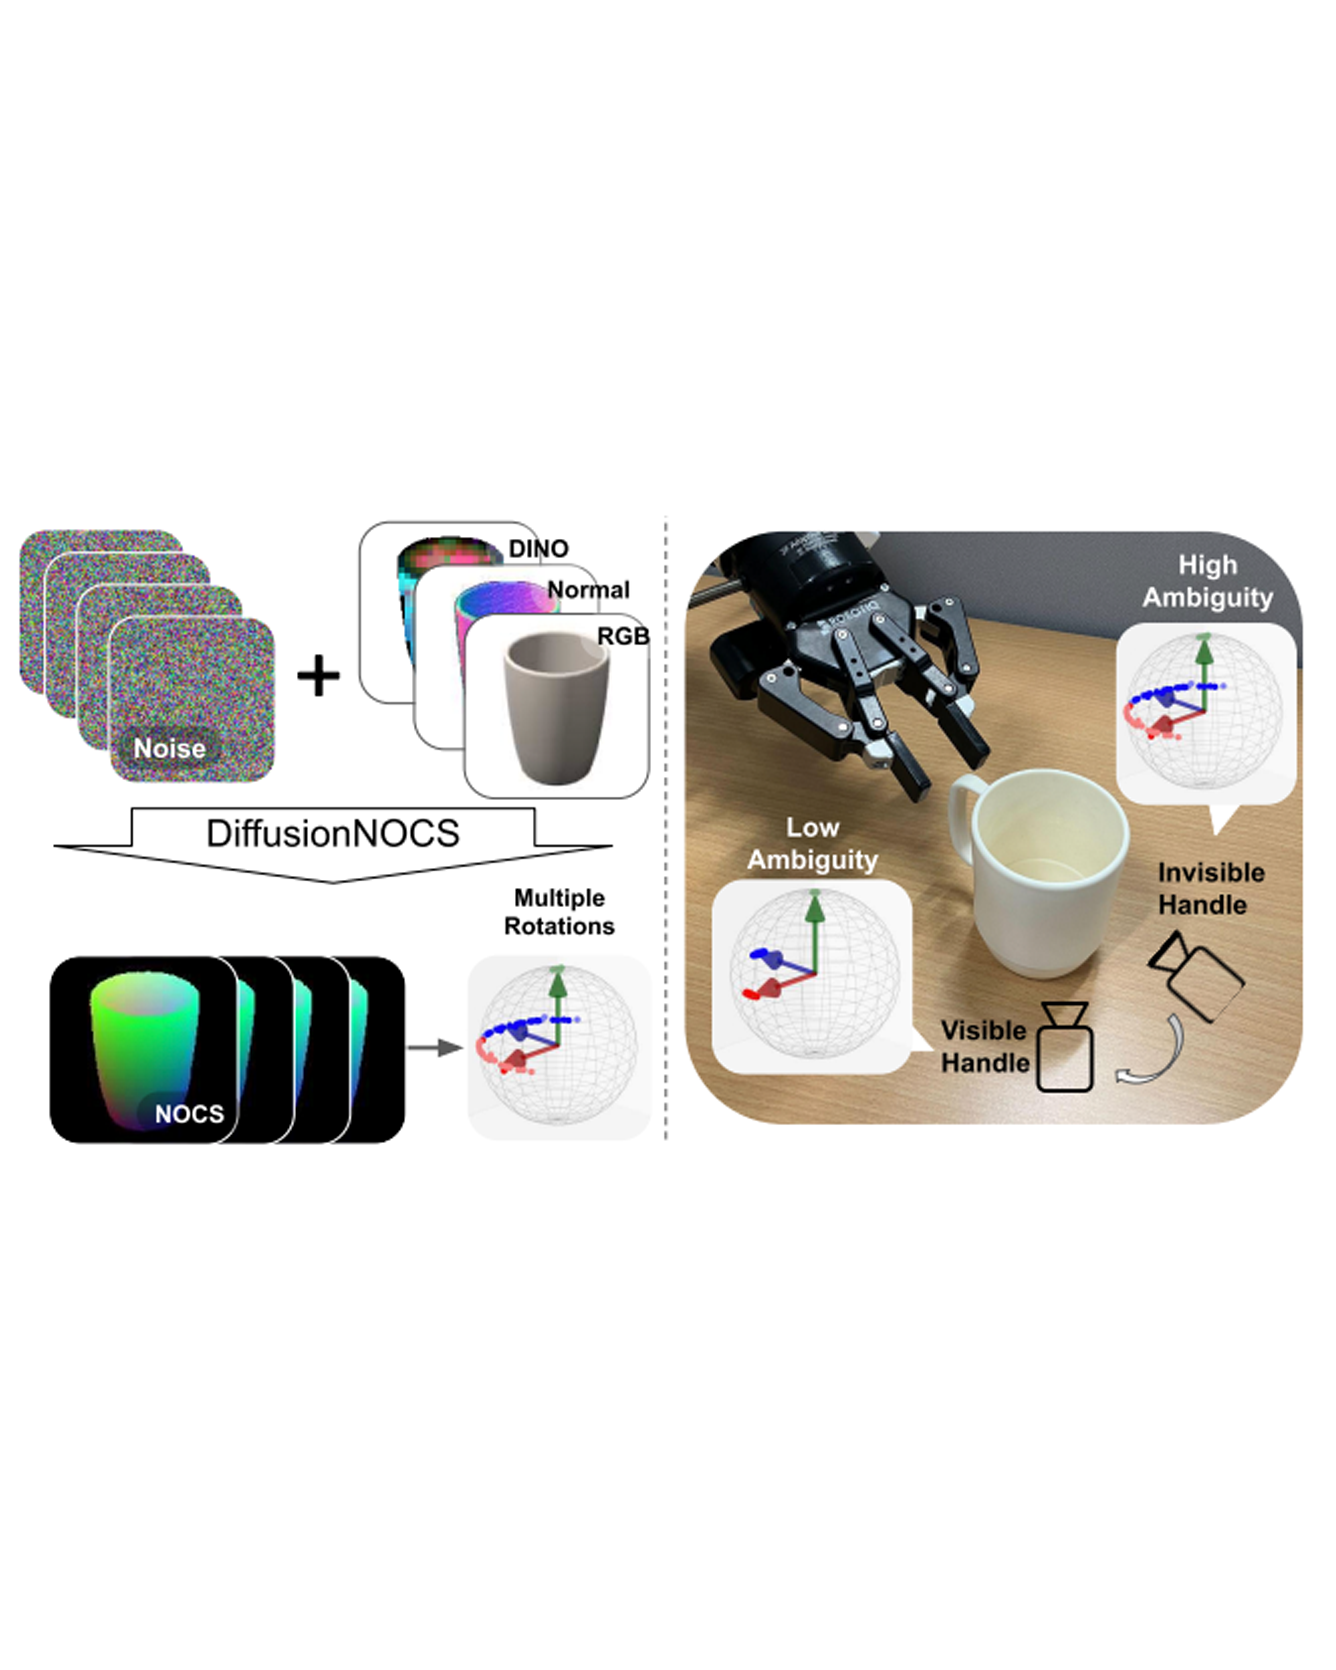
This paper addresses the challenging problem of category-level pose estimation. Current state-of-the-art methods for this task face challenges when dealing with symmetric objects and when attempting to generalize to new environments solely through synthetic data training. In this work, we address these challenges by proposing a probabilistic model that relies on diffusion to estimate dense canonical maps crucial for recovering partial object shapes as well as establishing correspondences essential for pose estimation. Furthermore, we introduce critical components to enhance performance by leveraging the strength of the diffusion models with multi-modal input representations. We demonstrate the effectiveness of our method by testing it on a range of real datasets. Despite being trained solely on our generated synthetic data, our approach achieves state-of-the-art performance and unprecedented generalization qualities, outperforming baselines, even those specifically trained on the target domain. READ MORE
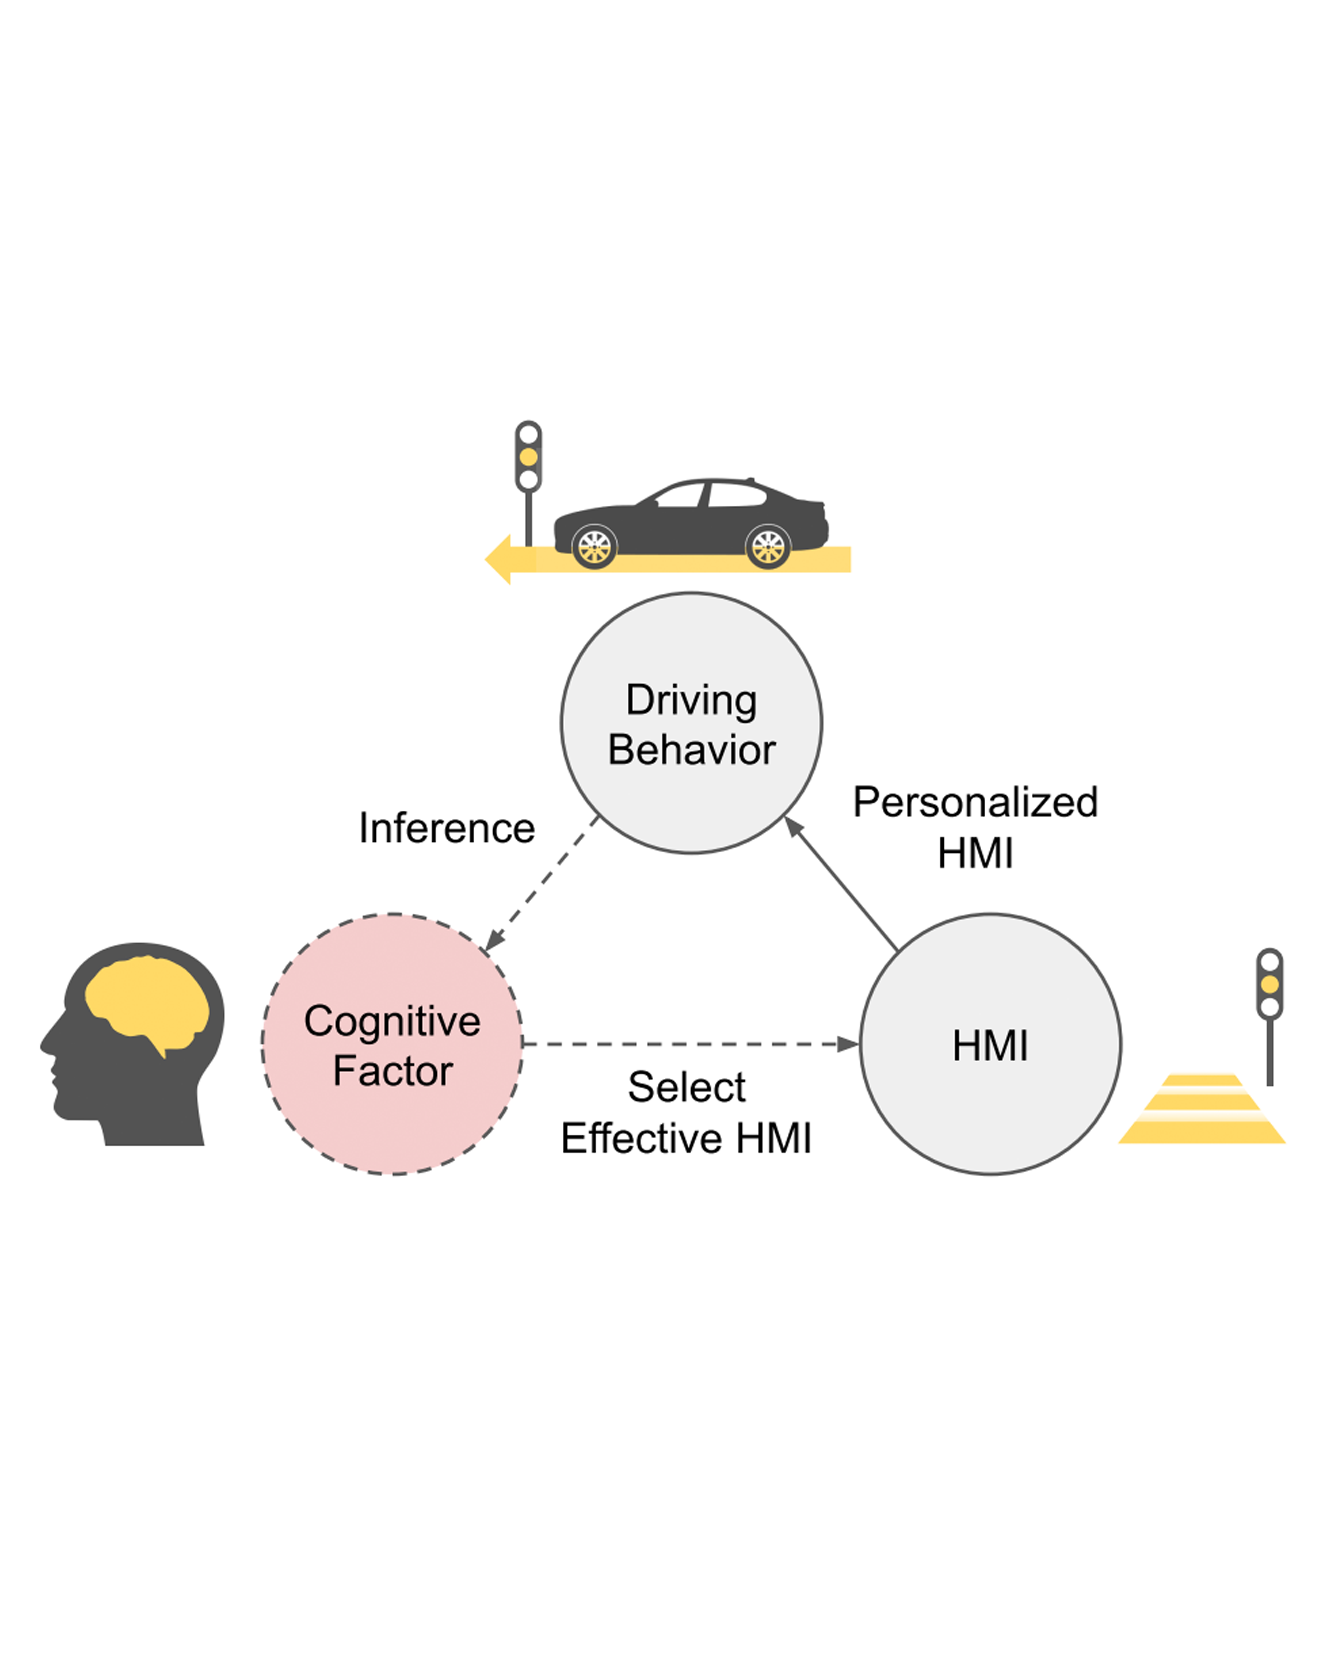
Recent advances in AI and intelligent vehicle technology hold promise to revolutionize mobility and transportation, in the form of advanced driving assistance (ADAS) interfaces. Although it is widely recognized that certain cognitive factors, such as impulsivity and inhibitory control, are related to risky driving behavior, play a significant role in on-road risk-taking, existing systems fail to leverage such factors. Varying levels of these cognitive factors could influence the effectiveness and acceptance of driver safety interfaces.
We demonstrate an approach for personalizing driver interaction via driver safety interfaces that are triggered based on a learned recurrent neural network. The network is trained from a population of human drivers to infer impulsivity and inhibitory control from recent driving behavior. Using a high-fidelity vehicle motion simulator, we demonstrate the ability to deduce these factors from driver behavior. We then use these inferred factors to make instantaneous determinations on whether or not to engage a driver safety interface. This interface aims to decrease a driver's speed during yellow lights and reduce their inclination to run through them. READ MORE
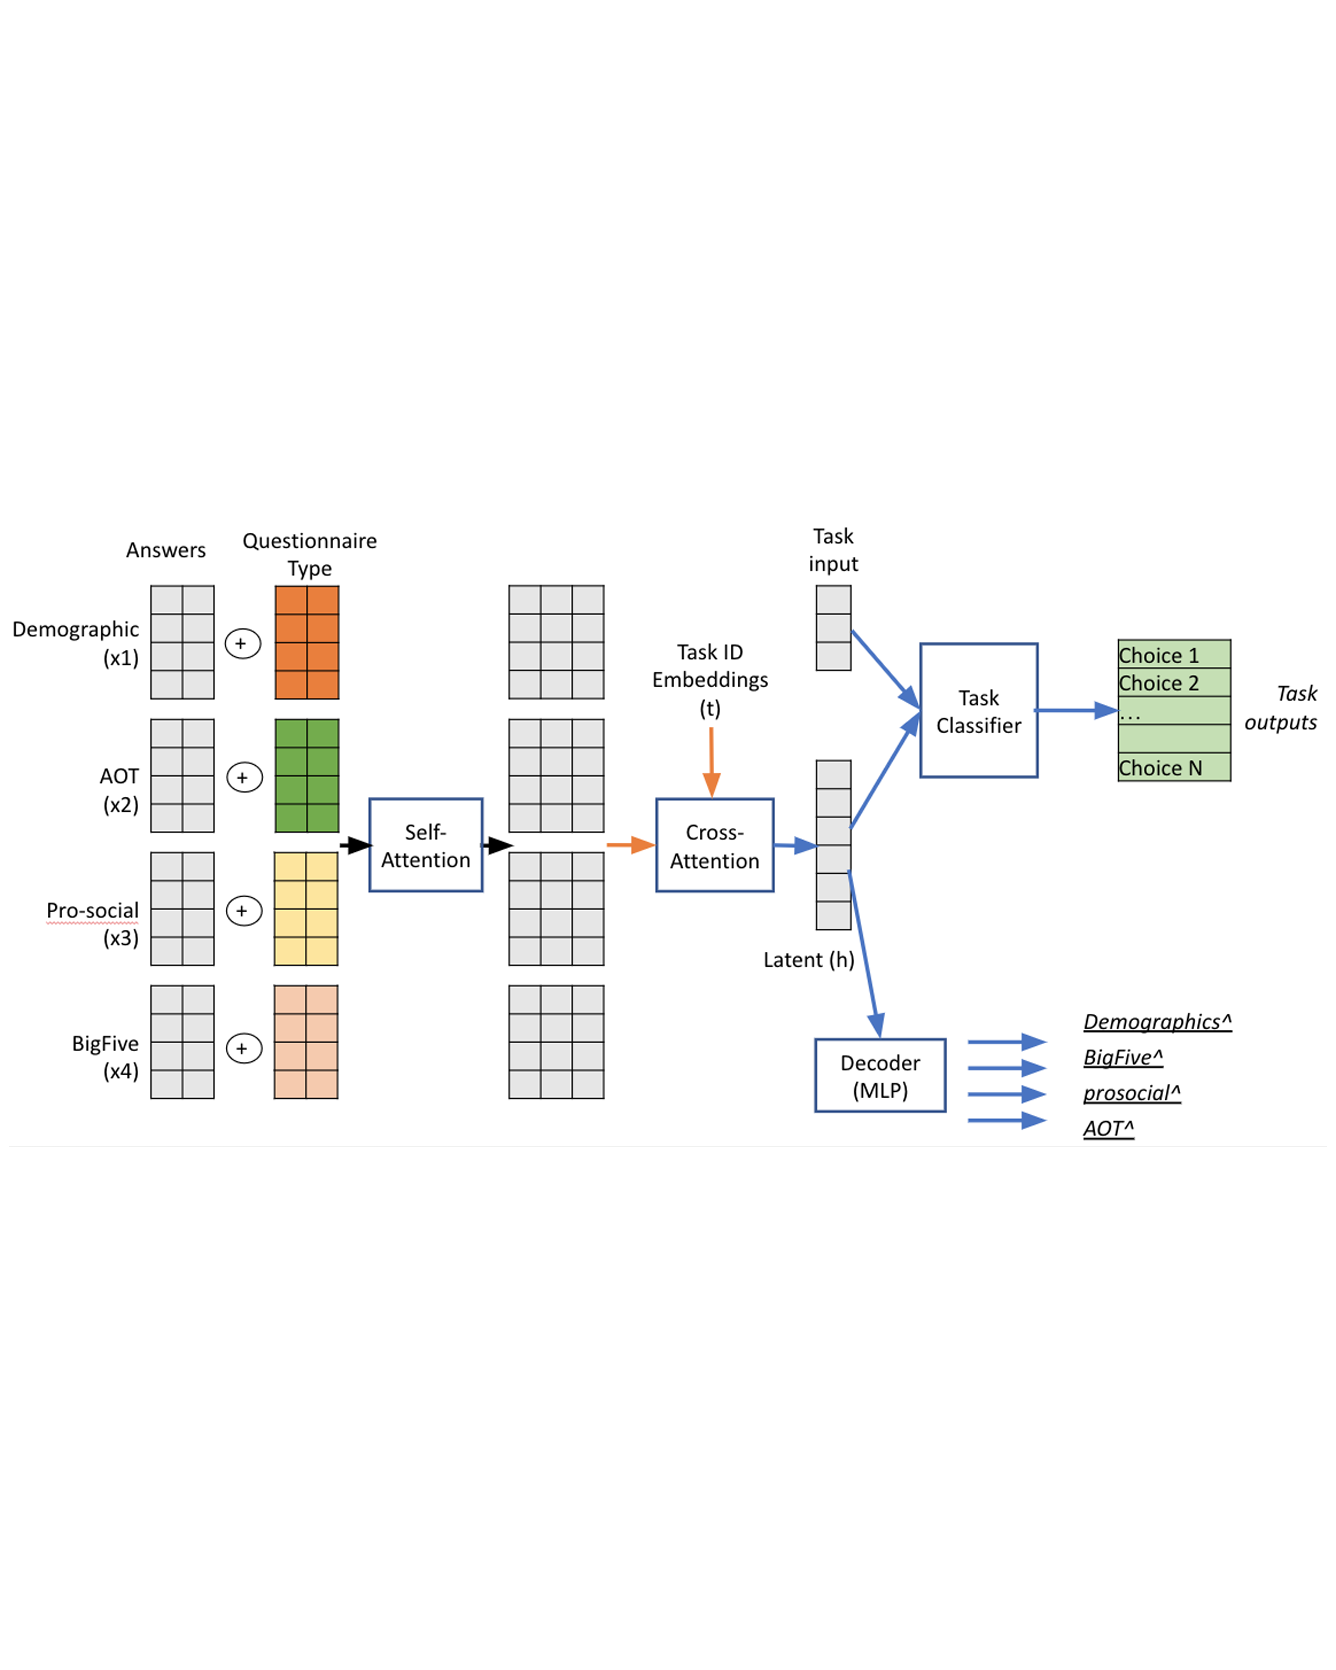
While most models of human choice are linear to ease interpretation, it is not clear whether linear models are good models of human decision-making. And while prior studies have investigated how task conditions and group characteristics, such as personality or socio-demographic background, influence human decisions, no prior works have investigated how to use less personal information for choice prediction. We propose a deep learning model based on self-attention and cross-attention to model human decision making which takes into account both subject-specific information and task conditions. We show that our model can consistently predict human decisions more accurately than linear models and other baseline models while remaining interpretable. In addition, although a larger amount of subject-specific information will generally lead to more accurate choice prediction, collecting more surveys to gather subject background information is a burden to subjects, as well as costly and time-consuming. To address this, we introduce a training scheme that reduces the number of surveys that must be collected in order to achieve more accurate predictions. READ MORE
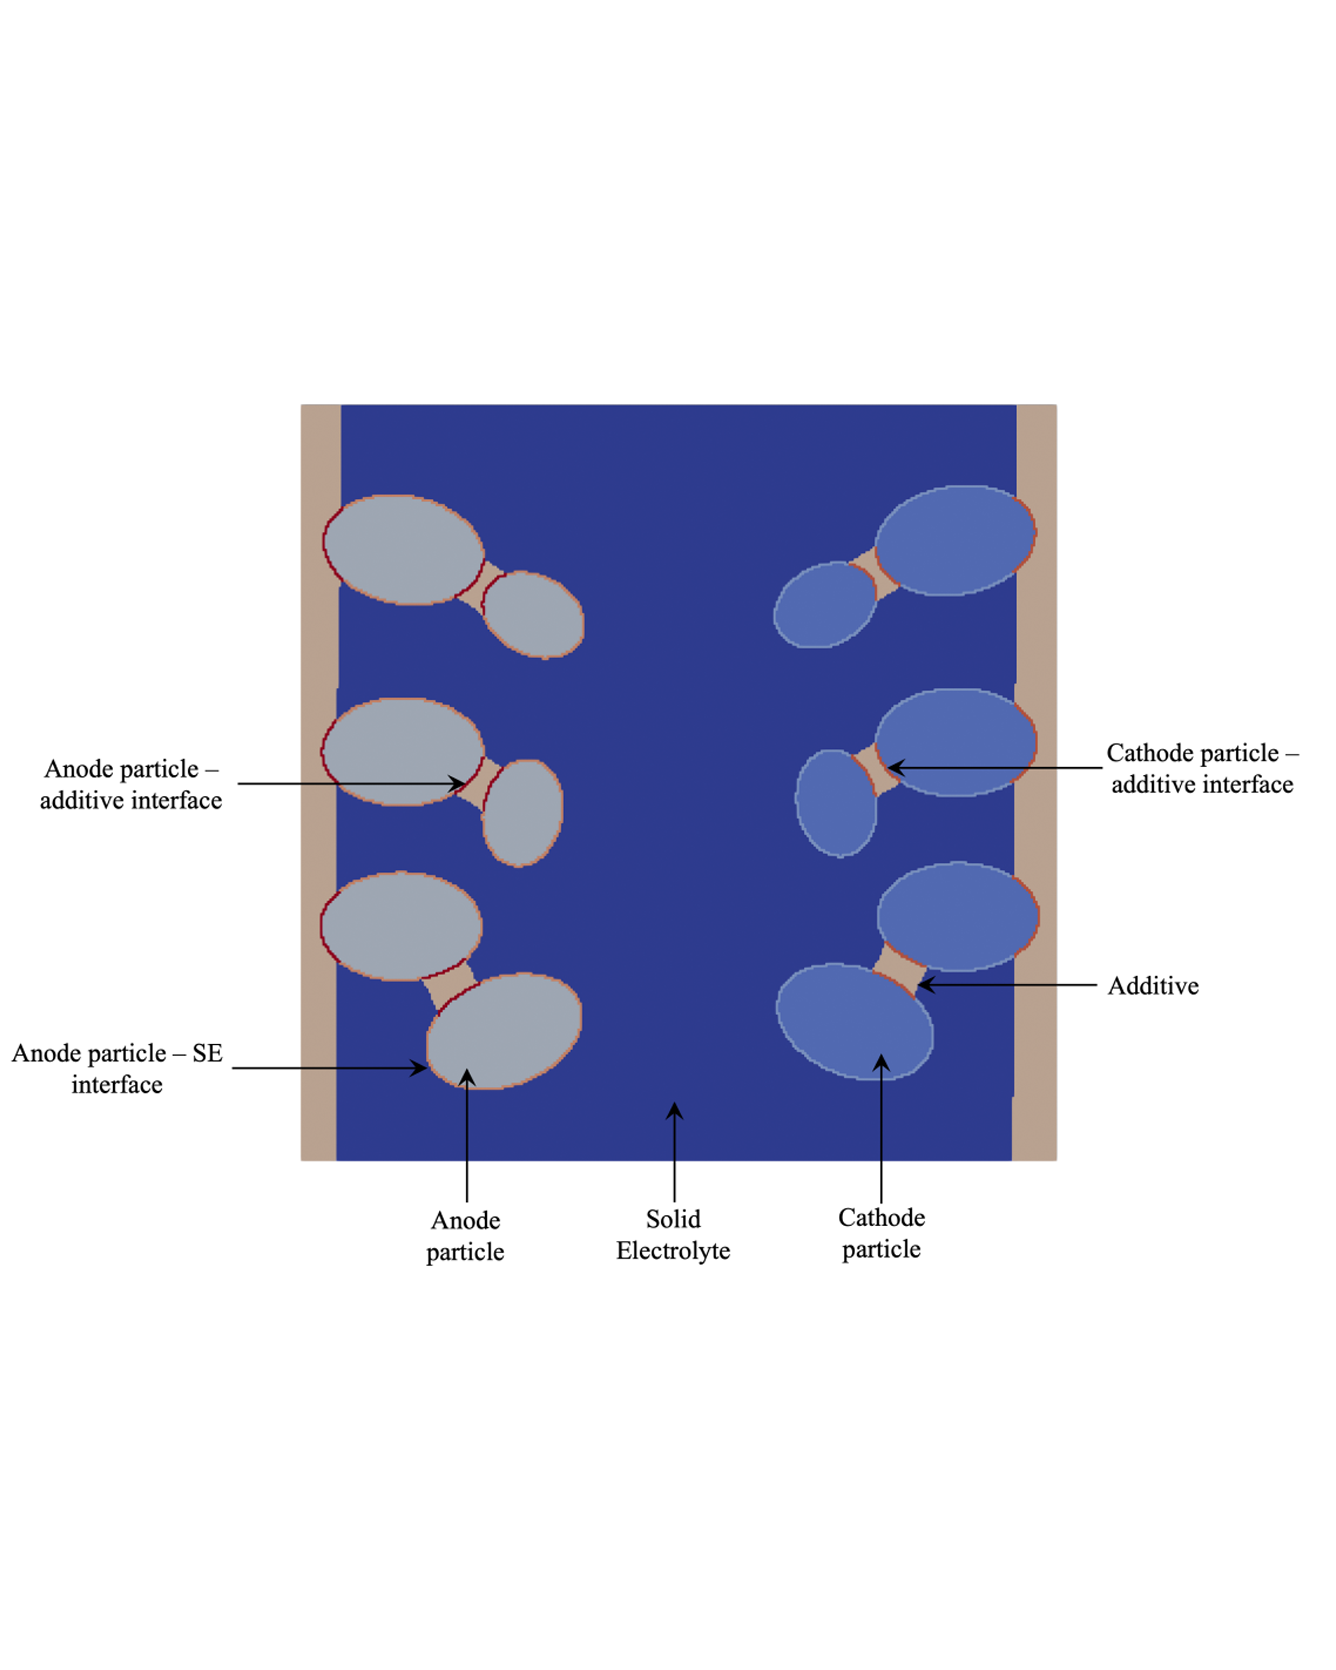
In this work, we present a computational framework for coupled electro-chemo-(nonlinear) mechanics at the particle scale for solid-state batteries. The framework accounts for interfacial fracture between the active particles and solid electrolyte due to intercalation stresses. We extend discontinuous finite element methods for a sharp interface treatment of discontinuities in concentrations, fluxes, electric fields and in displacements, the latter arising from active particle–solid electrolyte interface fracture. We model the degradation in the charge transfer process that results from the loss of contact due to fracture at the electrolyte–active particle interfaces. Additionally, we account for the stress-dependent kinetics that can influence the charge transfer reactions and solid state diffusion. The discontinuous finite element approach does not require a conformal mesh. This offers the flexibility to construct arbitrary particle shapes and geometries that are based on design, or are obtained from microscopy images. The finite element mesh, however, can remain Cartesian, and independent of the particle goemetries. We demonstrate this computational framework on micro-structures that are representative of solid-state batteries with single and multiple anode and cathode particles. READ MORE
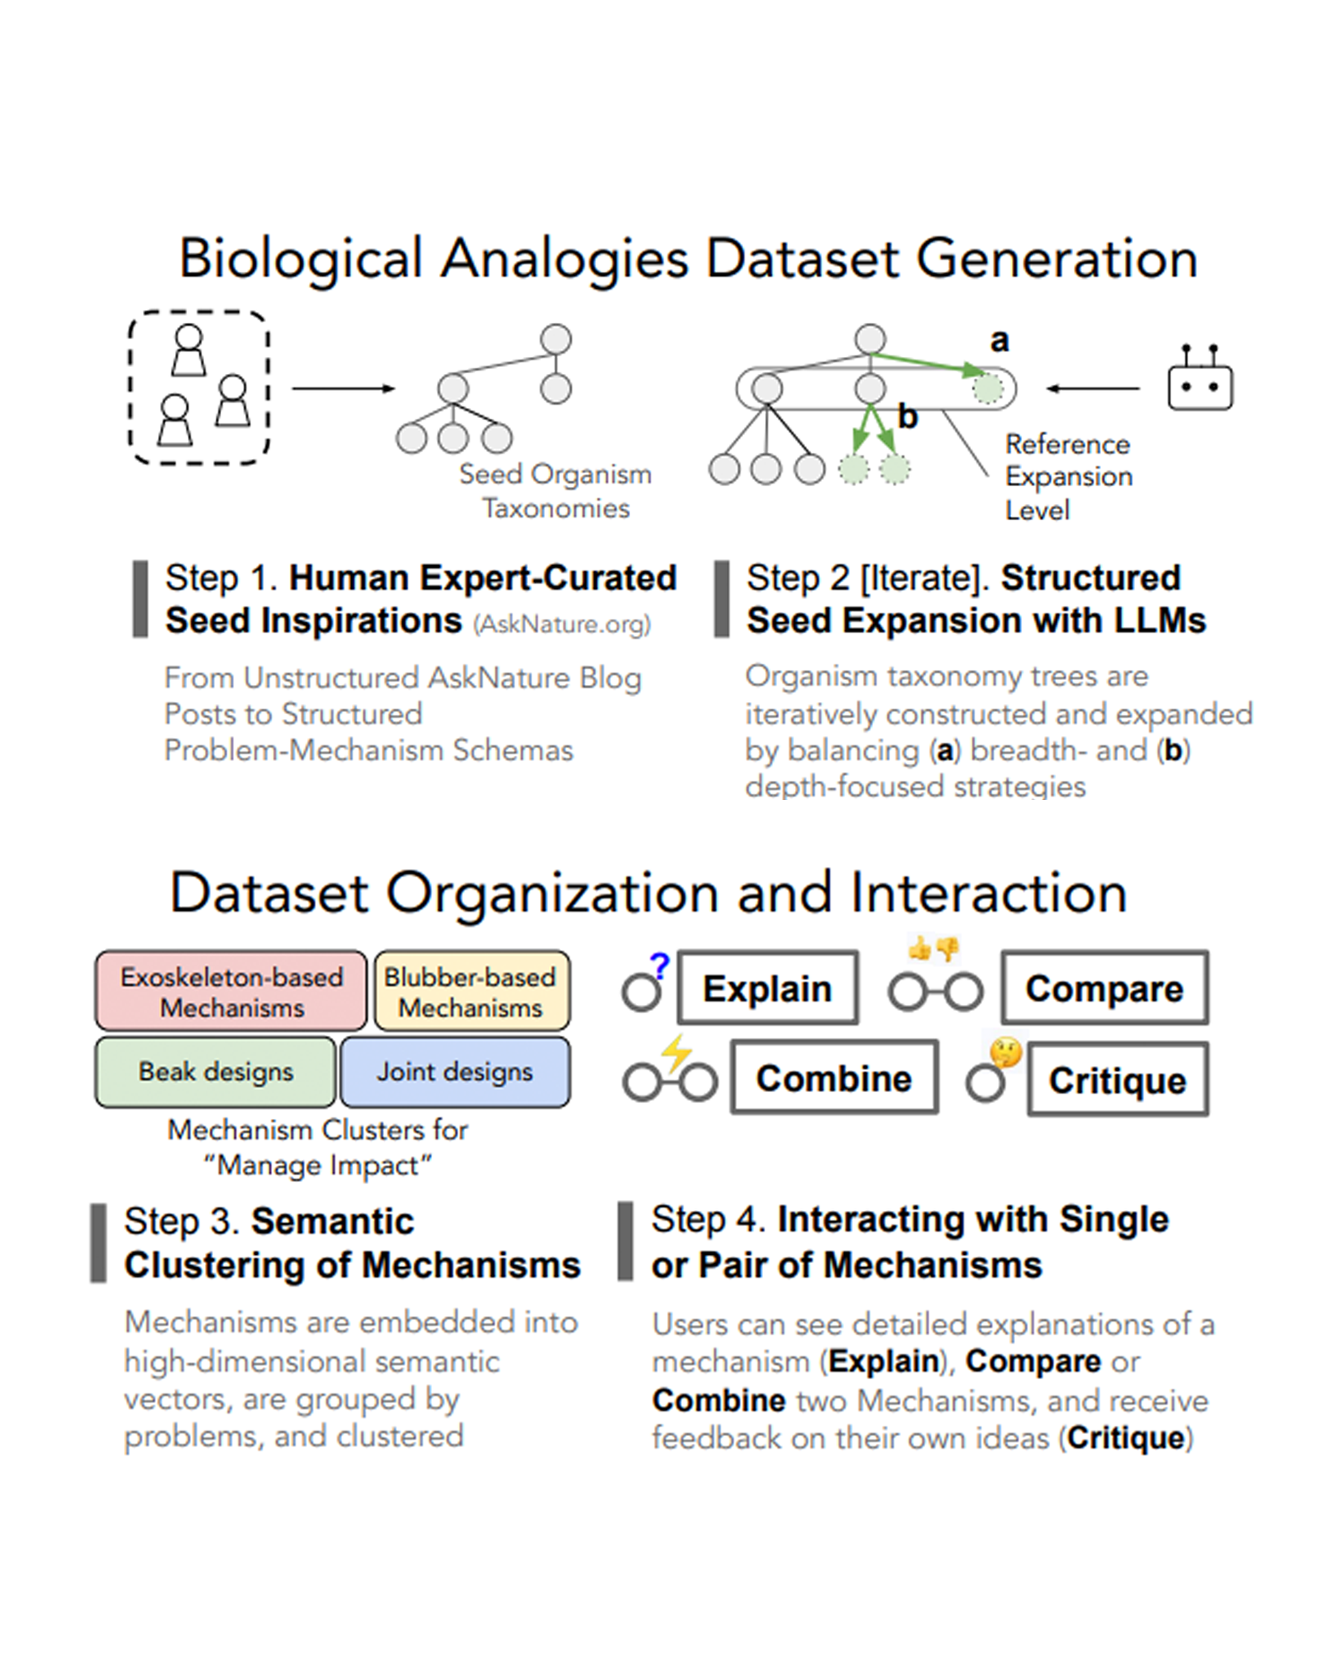
Nature is often used to inspire solutions for complex engineering problems, but achieving its full potential is challenging due to difficulties in discovering relevant analogies and synthesizing from them. Here, we present an end-to-end system, BioSpark, that generates biological-analogical mechanisms and provides an interactive interface to comprehend and synthesize from them. BioSpark pipeline starts with a small seed set of mechanisms and expands it using an iteratively constructed taxonomic hierarchies, overcoming data sparsity in manual expert curation and limited conceptual diversity in automated analogy generation via LLMs. The interface helps designers with recognizing and understanding relevant analogs to design problems using four main interaction features. We evaluate the biological-analogical mechanism generation pipeline and showcase the value of BioSpark through case studies. We end with discussion and implications for future work in this area. READ MORE
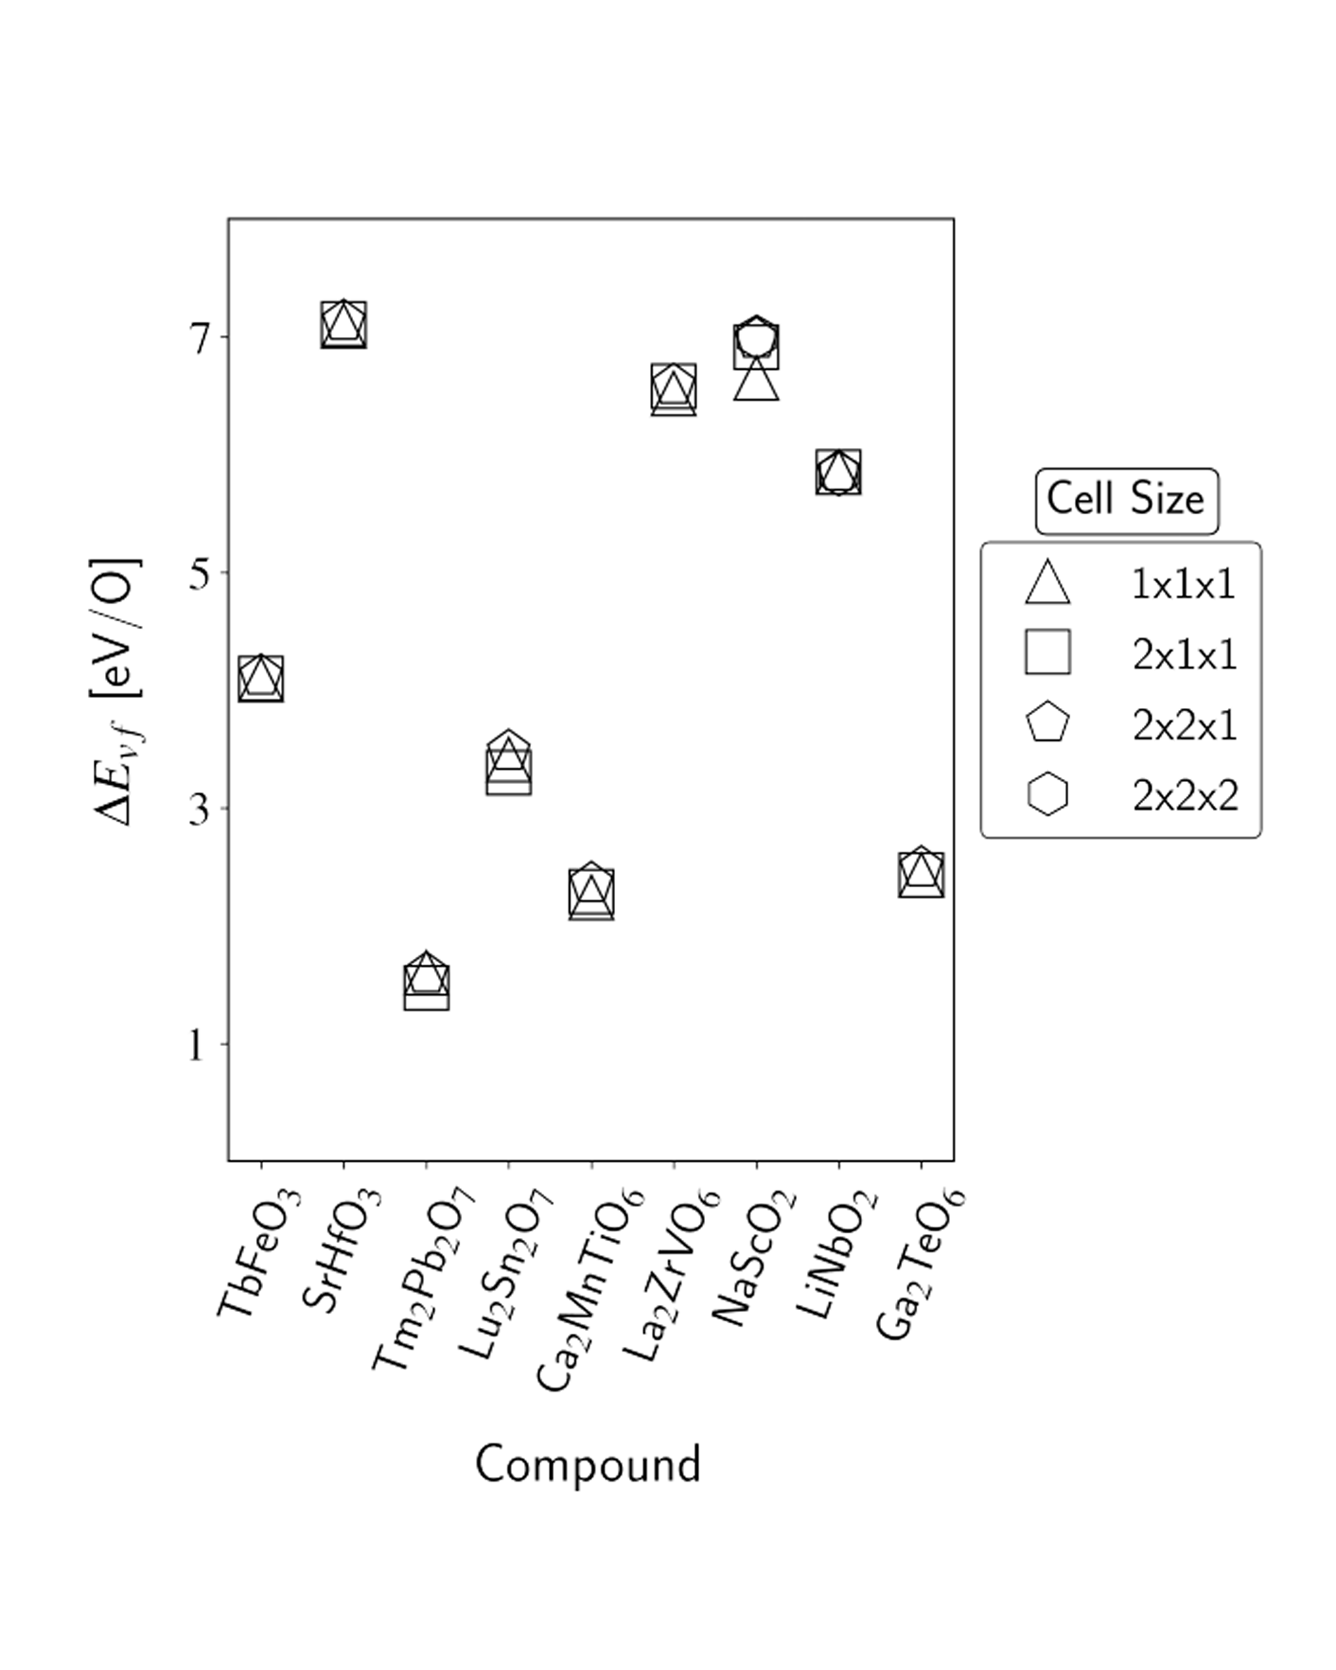
The oxygen vacancy formation energy (ΔEvf) governs defect concentrations alongside the entropy and is a useful metric to perform materials selection for a variety of applications. However, density functional theory (DFT) calculations of ΔEvf come at a greater computational cost than the typical bulk calculations available in materials databases due to the involvement of multiple vacancy-containing supercells. As a result, available repositories of direct calculations of ΔEvf remain relatively scarce, and the development of machine-learning models capable of delivering accurate predictions is of interest. In the present work, we address both such points. We first report the results of new high-throughput DFT calculations of oxygen vacancy formation energies of the different unique oxygen sites in over 1000 different oxide materials, with a large portion of the calculations, and of the discussion, focusing on perovskite-type and pyrochlore-type oxides. Together, the over 2500 ΔEvf calculations form the largest data set of directly computed oxygen vacancy formation energies to date, to our knowledge. We then utilize such a data set to train random forest models with different sets of features, examining both novel features introduced in this work and ones previously employed in the literature. We demonstrate the benefits of including features that contain information specific to the vacancy site and account for both cation identity and oxidation state and achieve a mean absolute error upon prediction of ∼0.3 eV/O, which is comparable to the accuracy observed upon comparison of DFT computations of oxygen vacancy formation energy and experimental results. Finally, we exemplify the predictive power of the developed models in the search for new compounds for solar-thermochemical water-splitting applications, finding over 250 new AA′BB′O6 double perovskite candidates. READ MORE
Automobile racing provides a unique and challenging environment for studying competitive multi-agent behavior. In creating autonomous racing agents, one consideration is the effect that modeling one’s opponents has on finding high-performance policies. In this paper, we study the overall effectiveness of opponent modeling in the context of autonomous racing, as well as the value of different information about one’s opponents. We propose a new approach for learning salient characteristics of one’s opponent: Learn Thy Enemy (LTE), an algorithmic framework that combines reinforcement learning with self-supervised learning about one’s opponents. We evaluate LTE against multiple baselines in a CARLA-based simulation of an actual major racetrack. The results demonstrate that LTE substantially outperforms baselines, showing LTE’s effectiveness in extracting relevant opponent information automatically during interactions with the aim of better accomplishing the task. READ MORE